
MECH 431 Midterm, Spring 2012
American University of Beirut · Control Systems · 5 pages



More MECH 431 files
Show the text of this exam
Midterm in
Control Engineering
MECH 435
Spring 2012
Duration: 90 minutes
Family name:
First name:
Student Id:
achieved
points
max.
points
P1
20
P2
20
P3
20
Total
60
MECH 435 Midterm Spring-2012 / Name/ID:
page 2
1
20 Pts (33%)
Given is a DC motor control system with cascaded position and velocity feedback:
Figure 1: DC motor control block diagram
The following parameters are given:
,
a)
What is the steady state error of the system to a step input?
b)
Determine the velocity error constant. What is the condition on
and
to ensure
a steady state error of
of the closed loop to a unit ramp input?
c)
Determine
and
such that the settling time is around 4 seconds (for the 2%
criterion) and the steady state error is
.
d)
What effect would it have, if
was negative?
¡
Km
¿ms + 1
Kv
¡
Kp
µr
µ
1
s
_µ
Kp
Kv
¿m = 0:5
Km = 1
Kv
Kp
ess = 0:01
ess = 0:01
Kv
MECH 435 Midterm Spring-2012 / Name/ID:
page 3
2
20 Pts (33%)
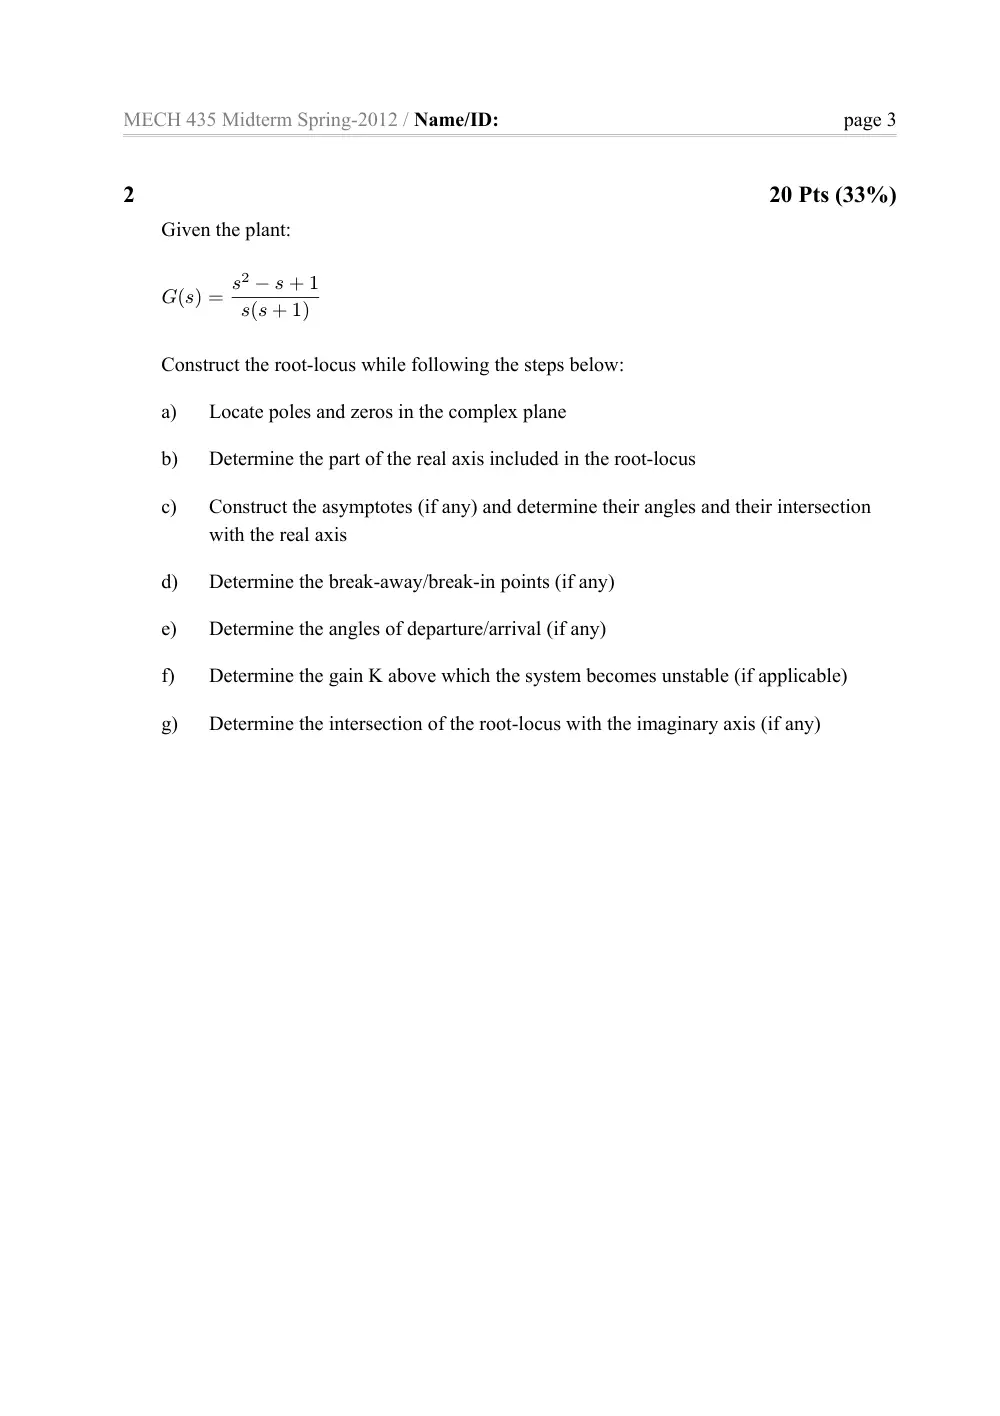
Given the plant:
Construct the root-locus while following the steps below:
a)
Locate poles and zeros in the complex plane
b)
Determine the part of the real axis included in the root-locus
c)
Construct the asymptotes (if any) and determine their angles and their intersection
with the real axis
d)
Determine the break-away/break-in points (if any)
e)
Determine the angles of departure/arrival (if any)
f)
Determine the gain K above which the system becomes unstable (if applicable)
g)
Determine the intersection of the root-locus with the imaginary axis (if any)
G(s) = s2 ¡ s + 1
s(s + 1)
MECH 435 Midterm Spring-2012 / Name/ID:
page 4
3
20 Pts (33%)
In this exercise we would like to control the plant
using the controller
and a
unity feedback. The setup is as shown in Figure 2 below:
Figure 2: Control Scheme of the plant G(s)
The transfer function of the plant
is given by:
The root locus of the plant
is given in Figure 3. We would like to design a controller
that achieves a settling time
seconds and a damping ratio
.
a)
Based on the root locus, show that it is not possible to satisfy the requirements stated
above using only a gain in the controller, i.e.,
Figure 3: Root Locus of the plant G(s)
G(s)
Gc(s)
G(s)
G(s) =
s + 2
s(s + 1)(s + 3)
G(s)
Ts = 2
» =
p
(2)=2
Gc(s) = K
MECH 435 Midterm Spring-2012 / Name/ID:
page 5
b)
Design a lead controller that achieves the requirements stated above
c)
Design a PD controller that achieves these same specifications