
EECE 340 Homework 5, Spring 2016
American University of Beirut · Signals and Systems · 4 pages · Prof. Karim Kabalan

More EECE 340 files
- Homework 3 · Spring 2016HomeworkView
- Homework 1 Solution · Spring 2016Homework · with solutionView
- Homework 4 · Spring 2016HomeworkView
- Homework 3 Solution · Spring 2016Homework · with solutionView
- Homework 4 Solution · Spring 2016Homework · with solutionView
- Homework 1 · Spring 2016HomeworkView
- Homework 2 Solution · Spring 2016Homework · with solutionView
- Homework 2 · Spring 2016HomeworkView
Show the text of this homework
AMERICAN UNIVERSITY OF BEIRUT
ELECTRICAL AND COMPUTER ENGINEERING DEPARTMENT
EECE 340
Homework V – Routh Hurwitz Stability Criterion
Problem 1
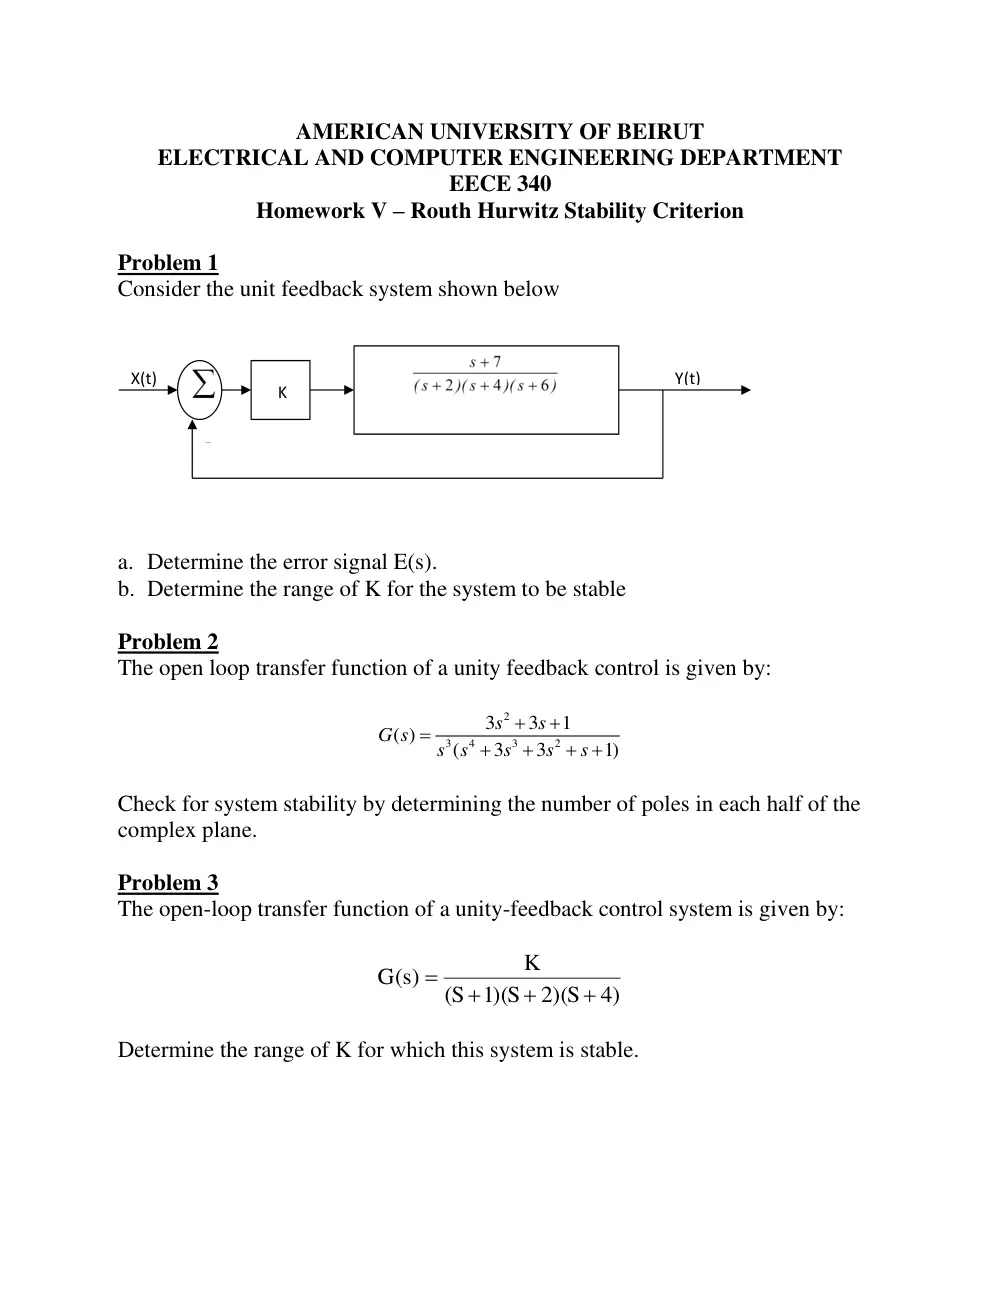
Consider the unit feedback system shown below
a. Determine the error signal E(s).
b. Determine the range of K for the system to be stable
Problem 2
The open loop transfer function of a unity feedback control is given by:
2
3
4
3
2
3
3
1
( )
(
3
3
1)
s
s
G s
s s
s
s
s
Check for system stability by determining the number of poles in each half of the
complex plane.
Problem 3
The open-loop transfer function of a unity-feedback control system is given by:
4)
2)(S
S 1)(S
(
K
G )s(
Determine the range of K for which this system is stable.
K
-
X(t)
Y(t)
Problem 4
The transfer function of an LTI system is given by
𝑌(𝑠)
𝑋(𝑠) =
𝑠 + 1
𝑠6 + 2𝑠5 + 3𝑠4 + 6𝑠3 + 2𝑠2 + 4𝑠 + 1
Where x(t) is the input and y(t) is the output. Determine the stability of the system
by determining the number of poles of the system in each half of the complex
plane.
Problem 5
The transfer function of a linear time-invariant system, whose input is x(t) and
output y(t), is given by
10
5s
3s
s
s
2
10
s
3
)s(
X
)s(
Y
2
3
4
Check the stability of the system by determining the number of poles of the system
in each half of the complex-plane.
Problem 6
The transfer function of a linear time-invariant system, whose input is x(t) and
output y(t), is given by
1
s
s
s
10
s
3
)s(
X
)s(
Y
3
4
Check the stability of the system by determining the number of poles of the system
in each half of the complex-plane.
Problem 7
The forward transfer function of a unity feedback control system is given by:
4)
2s
3s
s
s(s
)1
5 s(
)s(
G
2
3
4
Check the stability of the system by determining the number of poles in each half
of the complex plane.
Problem 8
The closed-loop transfer function of a unity feedback control system, whose input
is Y(s) and output is R(s), is given by
56
8s
42s
6s
7s
s
10
)s(
R
)s(
Y
2
3
4
5
Check the stability of the above system by determining the number of poles in each
half of the complex plane.
Problem 9
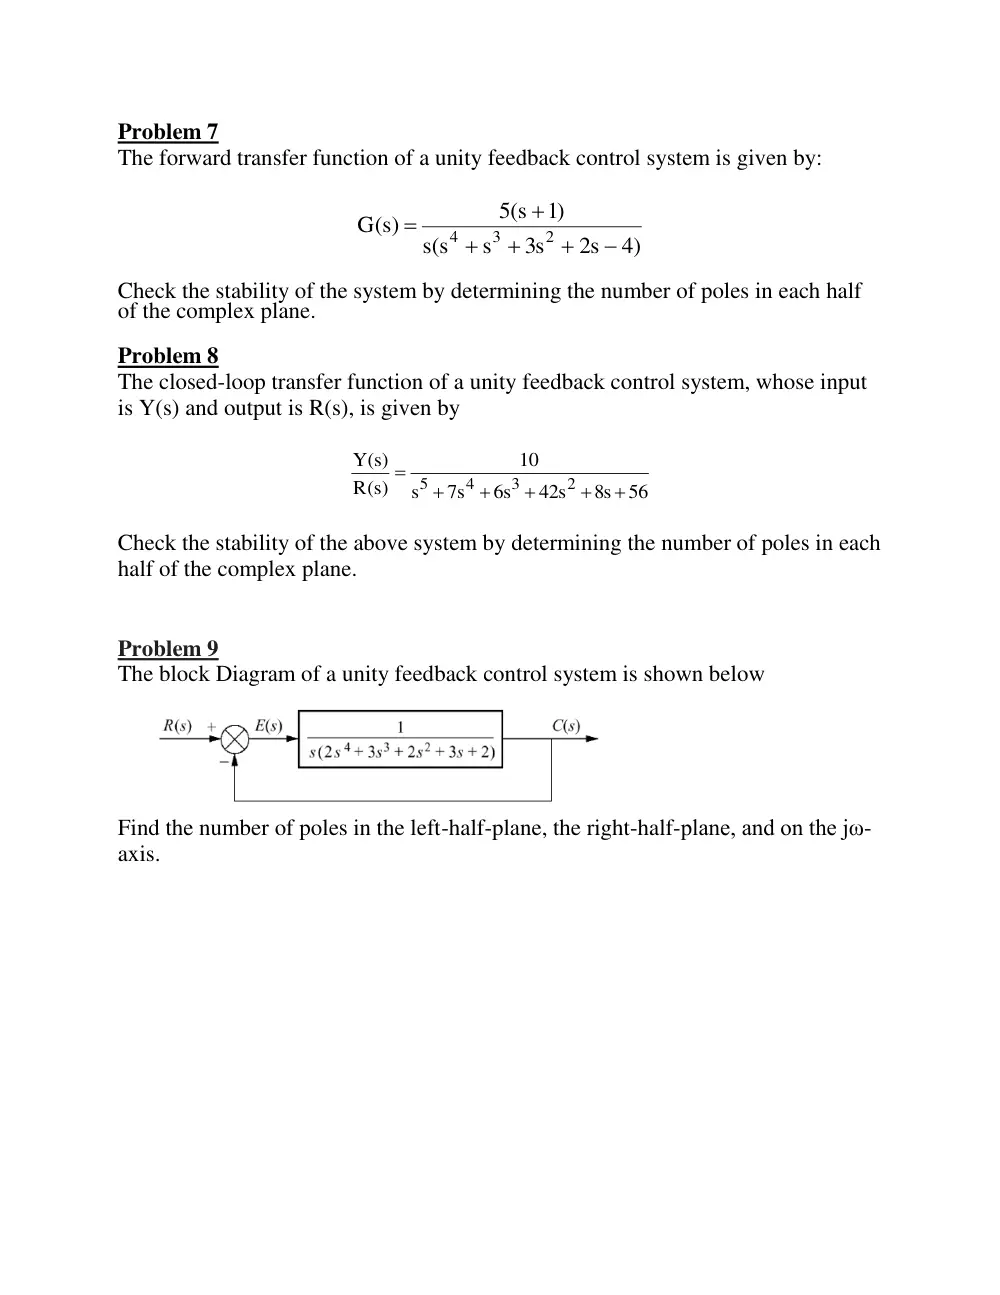
The block Diagram of a unity feedback control system is shown below
Find the number of poles in the left-half-plane, the right-half-plane, and on the jω-
axis.