
EECE 340 Problems with Solutions, Spring 2011
American University of Beirut · Signals and Systems · 5 pages · Prof. Karim Kabalan · with solution

More EECE 340 files
- Problems Book · Spring 2020ProblemsView
- Problems with Solutions · Spring 2011Problems · with solutionView
- Exam 2 · Spring 2017ExamView
- Exam 1 Kabalan · Spring 2017ExamView
- Exam 2 · Spring 2016ExamView
- Homework 1 Solution · Spring 2016Homework · with solutionView
- Homework 2 · Spring 2016HomeworkView
- Homework 2 Solution · Spring 2016Homework · with solutionView
Show the text of this problems
Review Problems
Problem 1
Given x[n] = h[n] = u[n - 1] – u[n – 5], find y[n] = x[n]*h[n] using z-
transforms
Problem 2
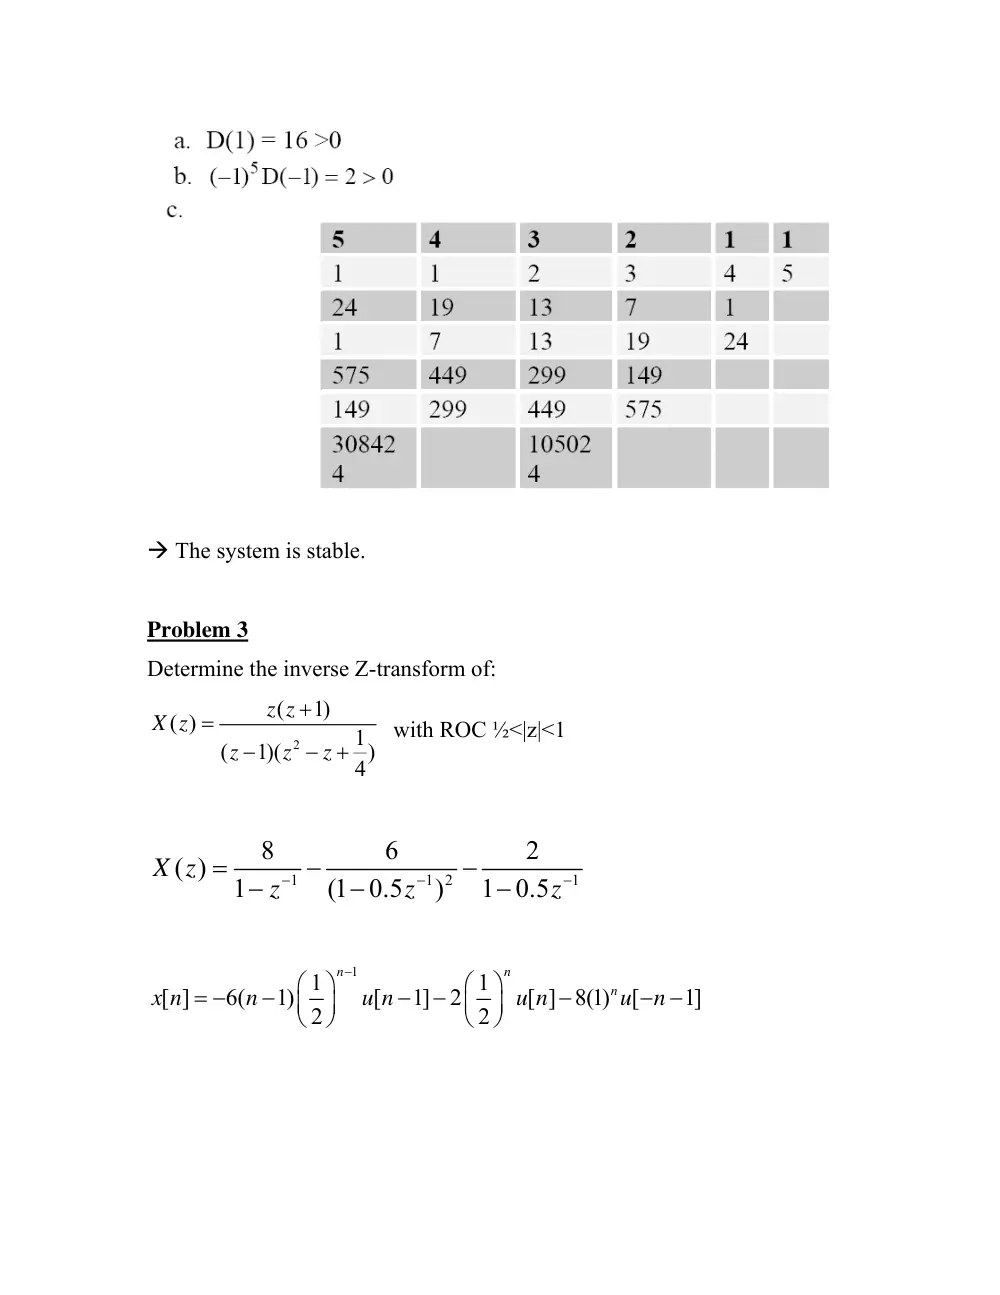
A recursive filter is given by:
6
2
5
4
3
2
2
1
( )
5
4
3
2
1
s
s
H z
z
z
z
z
z
+
+
=
+
+
+
+
+
Check the stability using Jury’s method
� The system is stable.
Problem 3
Determine the inverse Z-transform of:
2
(
1)
( )
1
(
1)(
)
4
z z
X z
z
z
z
+
=
−
−
+
with ROC ½<|z|<1
1
1 2
1
8
6
2
( )
1
(1 0.5
)
1 0.5
X z
z
z
z
−
−
−
=
−
−
−
−
−
1
1
1
[ ]
6(
1)
[
1]
2
[ ] 8(1)
[
1]
2
2
n
n
n
x n
n
u n
u n
u
n
−
⎛
⎞
⎛
⎞
= −
−
−
−
−
− −
⎜
⎟
⎜
⎟
⎝
⎠
⎝
⎠
Problem 4
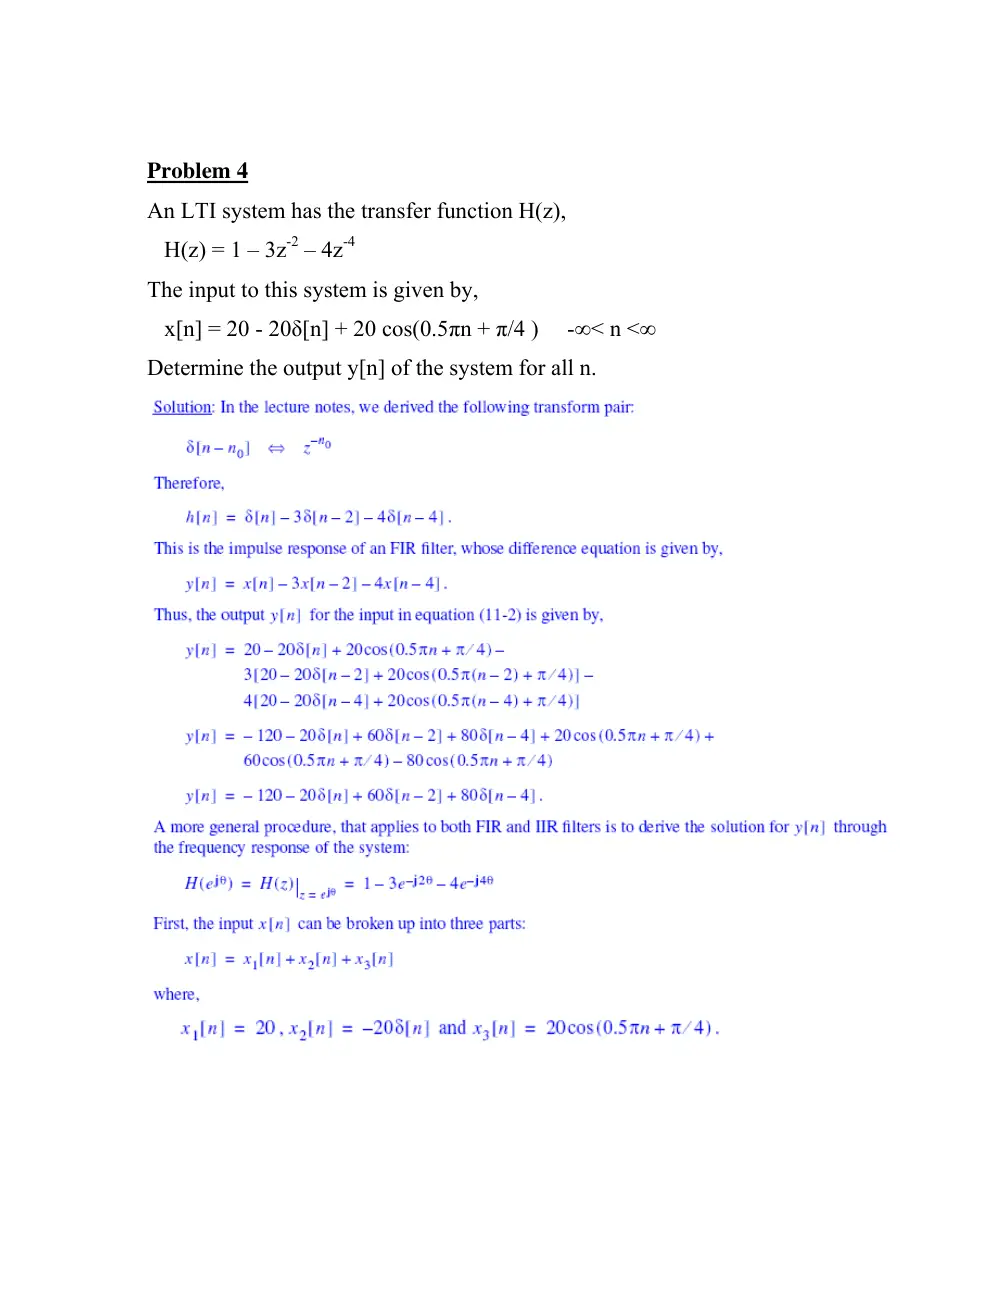
An LTI system has the transfer function H(z),
H(z) = 1 – 3z-2 – 4z-4
The input to this system is given by,
x[n] = 20 - 20δ[n] + 20 cos(0.5πn + π/4 ) -∞< n <∞
Determine the output y[n] of the system for all n.
Problem 5
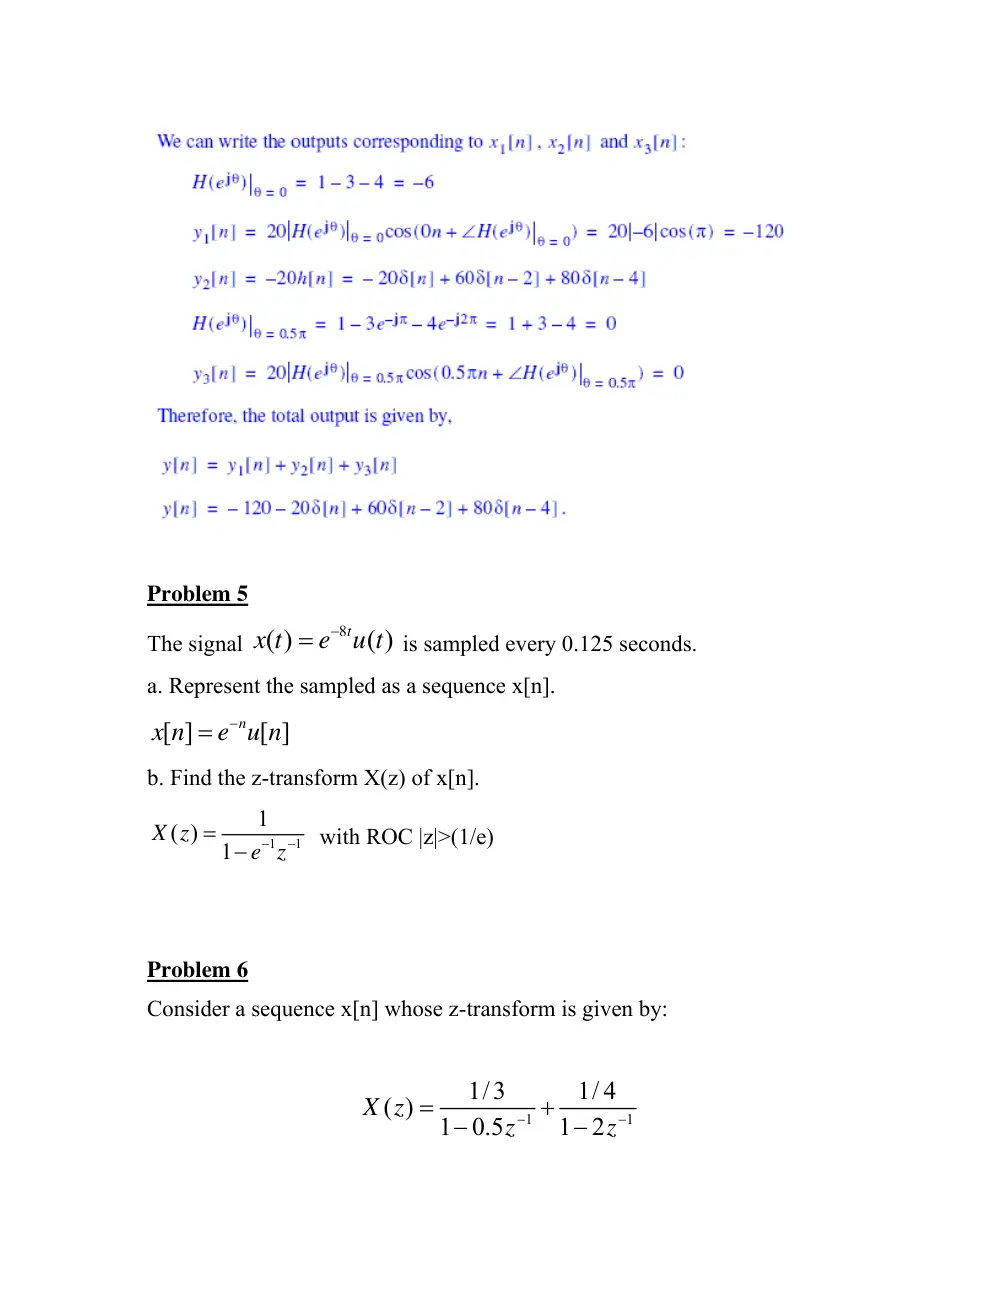
The signal
8
( )
t ( )
x t
e
= − u t
is sampled every 0.125 seconds.
a. Represent the sampled as a sequence x[n].
[ ]
n [ ]
x n
e u n
= −
b. Find the z-transform X(z) of x[n].
1
1
1
( )
1
X z
e z
−
−
= −
with ROC |z|>(1/e)
Problem 6
Consider a sequence x[n] whose z-transform is given by:
1
1
1/3
1/ 4
( )
1 0.5
1
2
X z
z
z
−
−
=
+
−
−
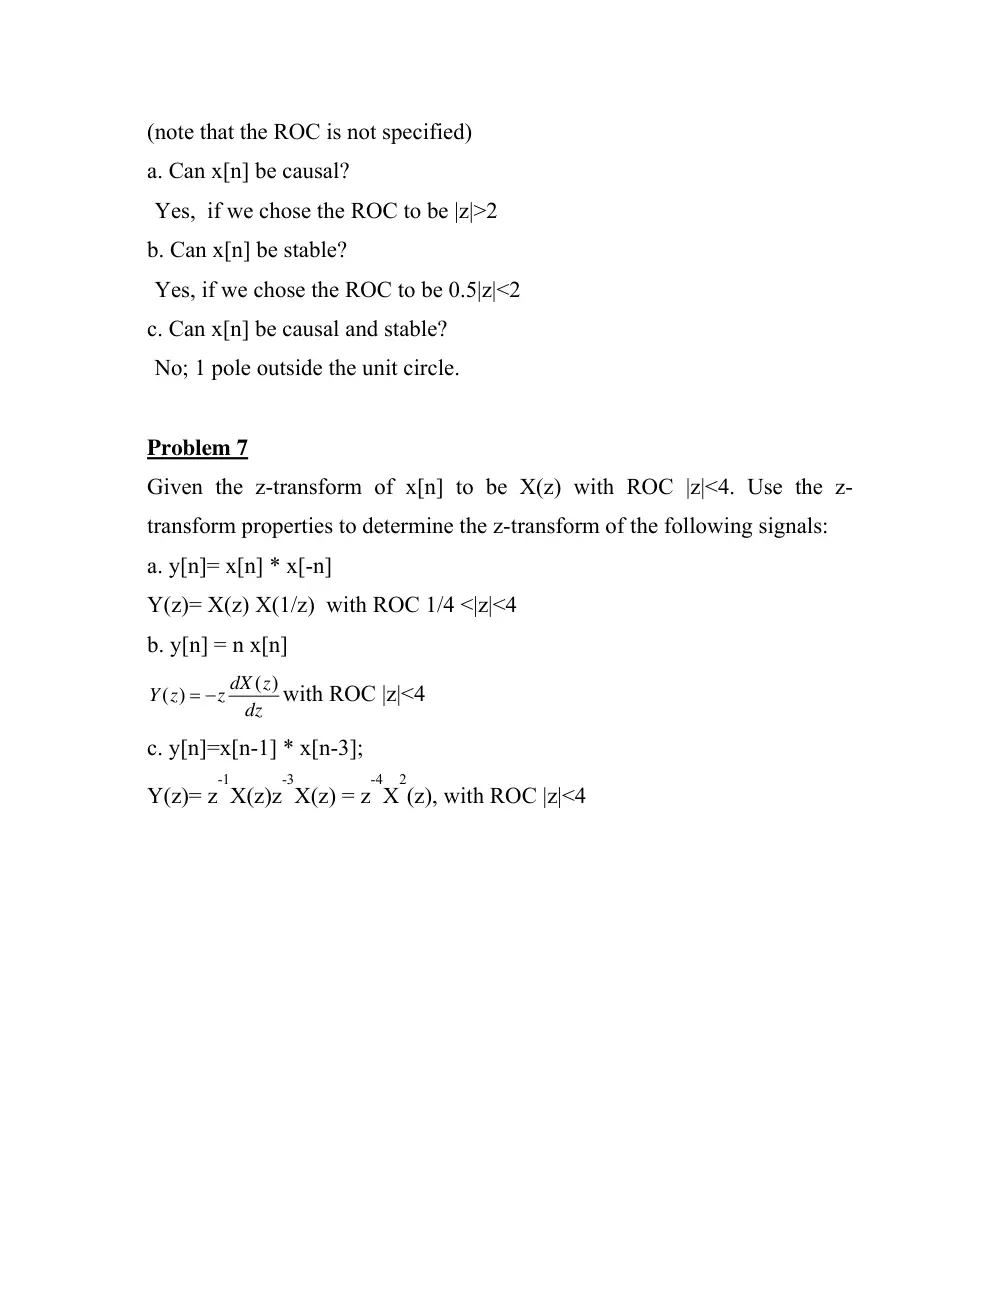
(note that the ROC is not specified)
a. Can x[n] be causal?
Yes, if we chose the ROC to be |z|>2
b. Can x[n] be stable?
Yes, if we chose the ROC to be 0.5|z|<2
c. Can x[n] be causal and stable?
No; 1 pole outside the unit circle.
Problem 7
Given the z-transform of x[n] to be X(z) with ROC |z|<4. Use the z-
transform properties to determine the z-transform of the following signals:
a. y[n]= x[n] * x[-n]
Y(z)= X(z) X(1/z) with ROC 1/4 <|z|<4
b. y[n] = n x[n]
( )
( )
dX z
Y z
z
dz
= −
with ROC |z|<4
c. y[n]=x[n-1] * x[n-3];
Y(z)= z
-1
X(z)z
-3
X(z) = z
-4
X
2
(z), with ROC |z|<4