
EECE 460 Homework, Spring 2007
American University of Beirut · Control Systems · 8 pages
More EECE 460 files
Show the text of this homework
F. Mrad EECE 460 Spring 2007
Homework # 9 Solution (Exercises 12.3, 8, 11 & 14)
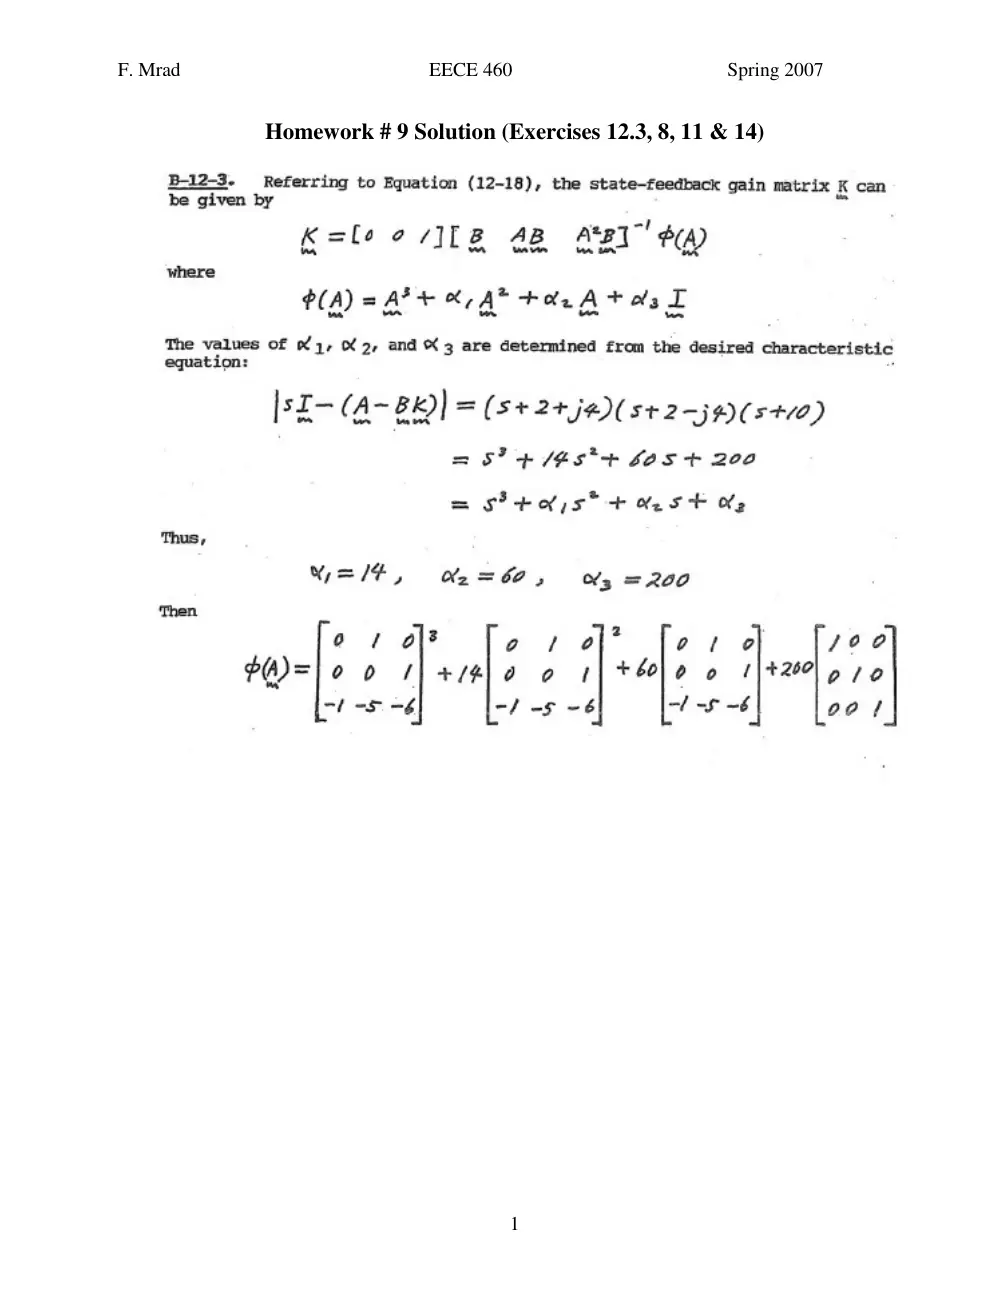
Beiz-3- = Referring to Equation (12-18), the state-feedback gain matrix K can
be be given by
Klee vIle 4B Ati tm
(A) = APY Kp A* +a. Atos I
The values of 1, 9, and &3 are determined from the desired characteristic
eguation:
hea BK) = (St24+ja)(st2-ja)(st10)
= 5S? 4 /¥s*+ S85 + 200
= Stolys* + West Oy
Thus,
WH/t, Wn =be, Ws = 200
Then
a7 afF of @ ele foo
eA) (| +141 e a 1] +80) 0 0 142% po
F. Mrad EECE 460 Spring 2007
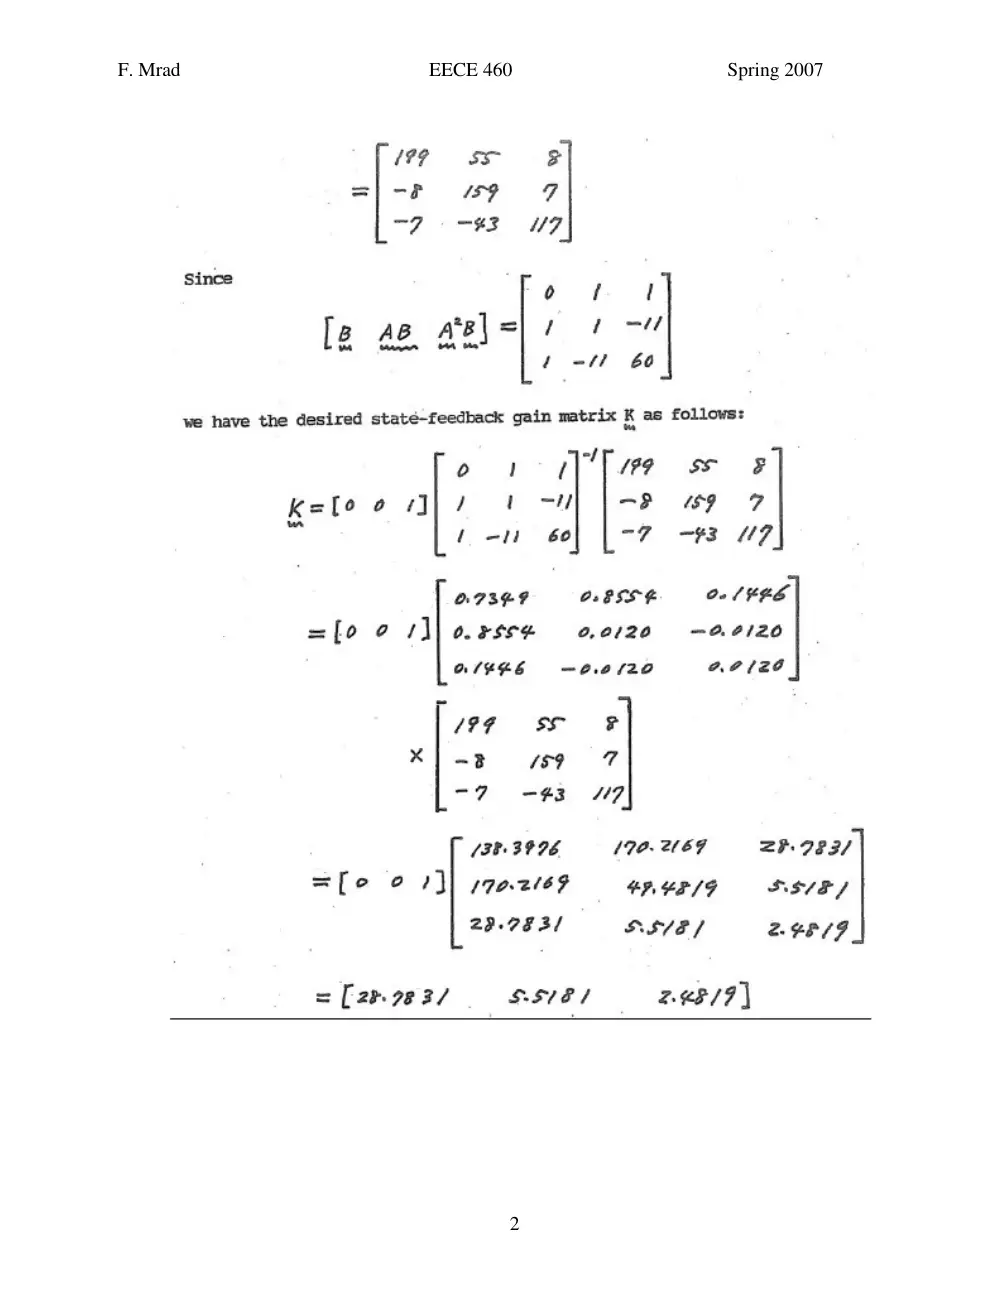
=|-5 sp 9
—~F =—¢3 WF
Since :
a) f {
[e ae atela| er mw
f =-f/ 64
we have the desired state-feedback gain matrix K as follows:
oo! i 179) FF
Ke[o@ ry]} / ft ma -3 9 F
f -l 66 “7 <-'3 7
aAP7aeF Os FT ¢. Os f FES
=[o o sll oesse 00120 -00120
OleEes —@.8/28 ee f2e
47% SS Ff
X/-3 «59 7
-F -€3 “#9
(9B 3996 190.269 = ZA 7E3/
ale OIF) r7026F — apye/g | SEES
23.783/ SSE f 2 ¢P SF
=[2r7¢3/ $578/ 2.48/97)
F. Mrad EECE 460 Spring 2007
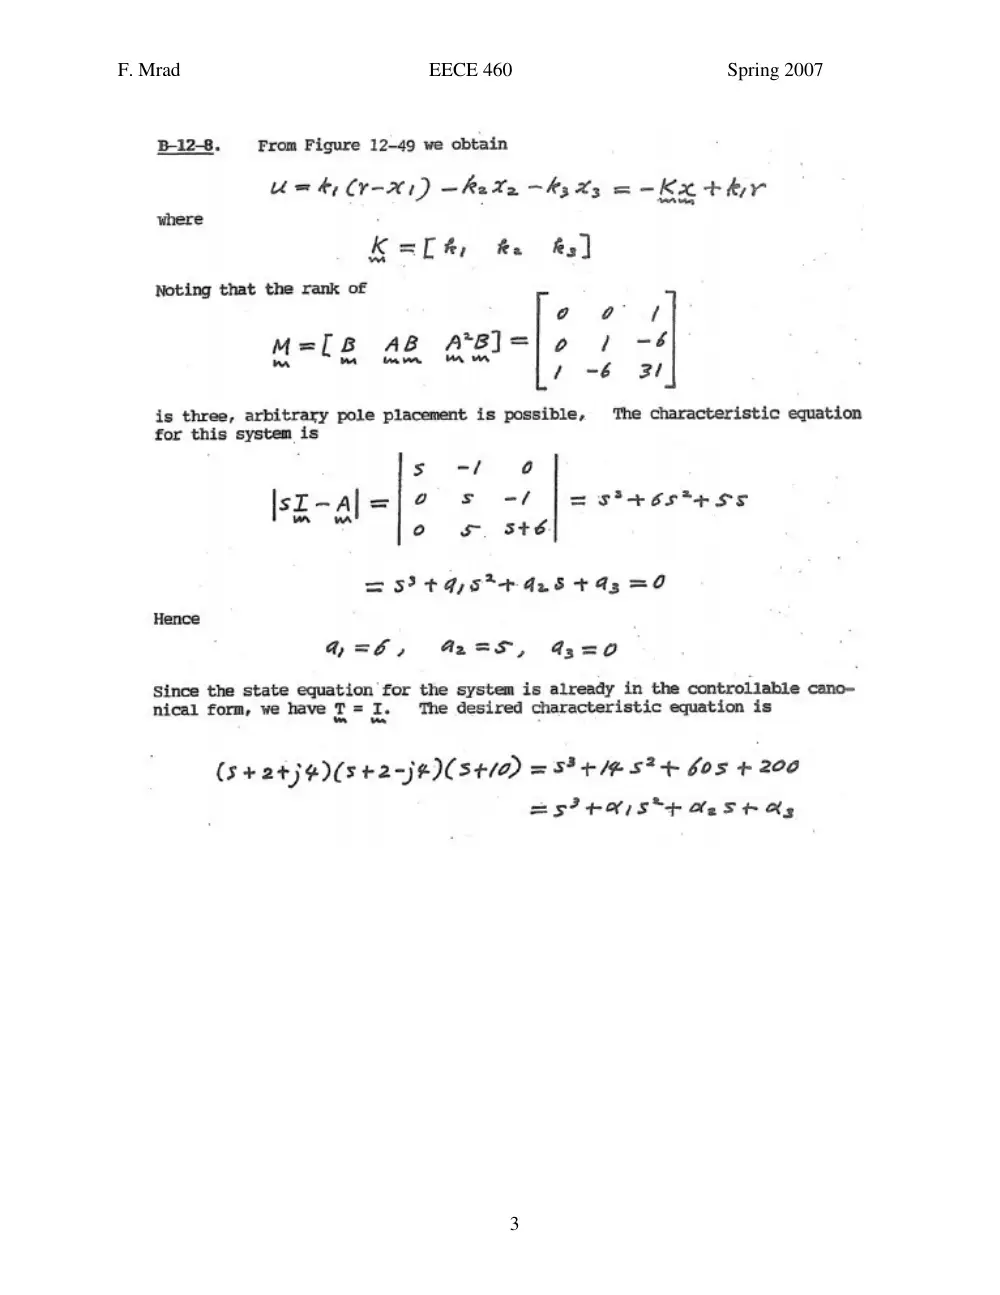
B-12-8. From Figure 12-49 we obtain
us &; Cr-%1) —ReX —A32X3 = - Ke +r
K=D#, Ra Rs |
Noting that the rank of .
ef
e
= ios = -é
male ag geln|e 1 =
is three, arbitrary pole placement is possible, The characteristic equation
for this system is
s -=/ é
|sZ-al= oo s =f |= staés*+ ss
WA A
o Ss Sté
=e tas s+ 48 +43 =9
a =f,» 4,=5, @z,=0
Since the state equation for the system is already in the controllable cano-
nical form, we have T = is The desired characteristic equation is
(se atjel(st2je(stiD =S+/4s*+ 605 + 200
Sst rr s*+ obese As
F. Mrad EECE 460 Spring 2007
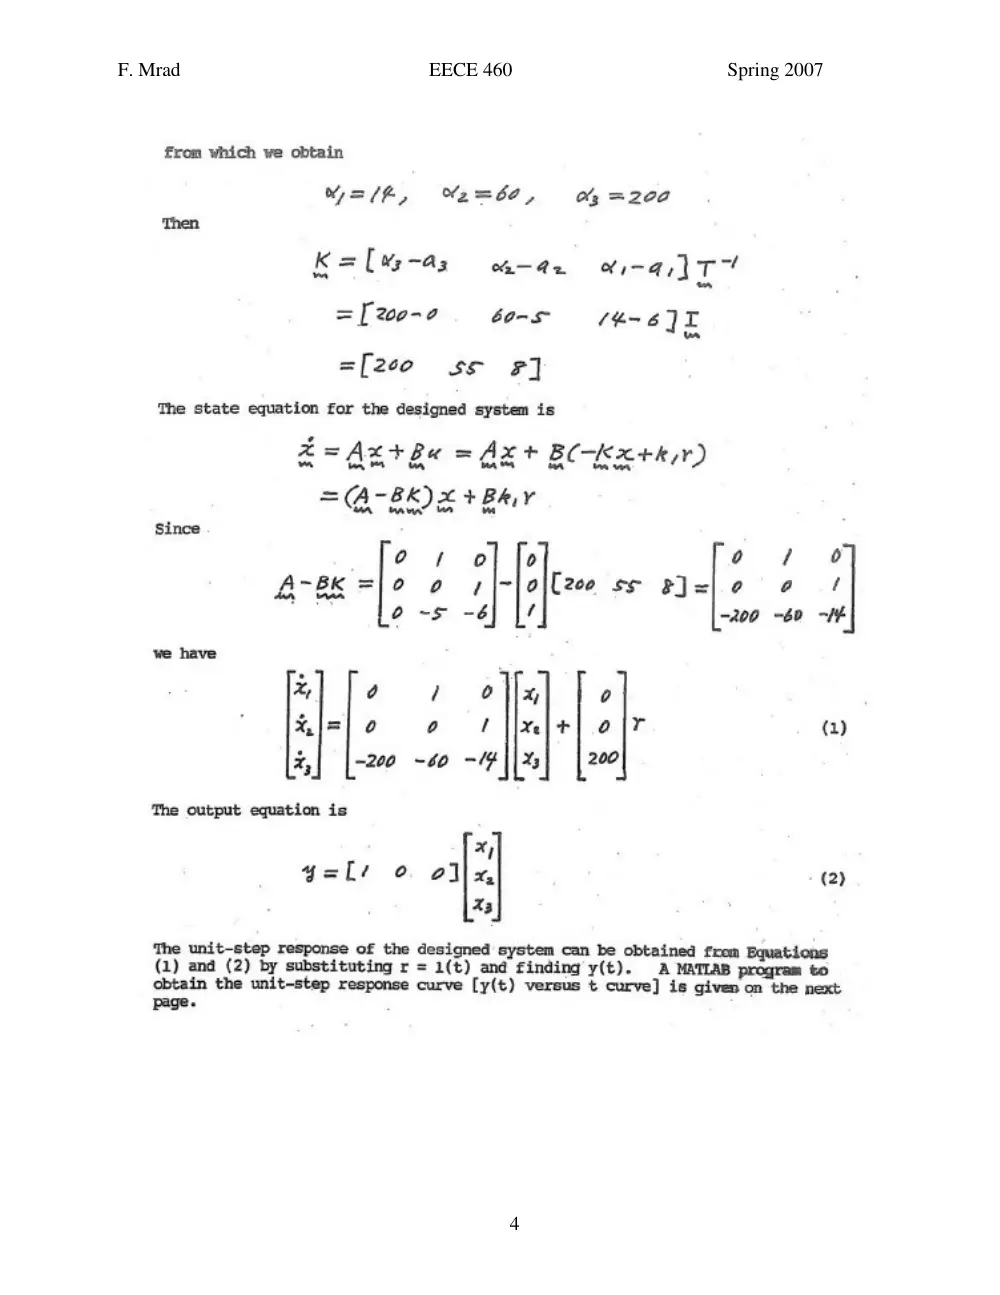
from which we obtain
Mele, “2=b?, of =200
K=([%-43) -a@e ot)-4,]T7
= [200-0 be-5 (4-6 ]T
=[200 s5 #]
The state equation for the designed system is
Z=Axt Be = Axt BC-Kx+kr)
™~
= QED E+ BAY
Since .
oO +f of fo oa f 6
A-BK =|0 0 7 \-|o|[20e ss e]=|e o 7
_“ @~s -é} [/ -200 -é0 =H
we have
x é i © IIx, re
X=! 0 of \ixelt] apr (1)
x,| |-200 -00 -/¢||% 200
The output equation is
ay ;
yal’ @ allx, (2)
43
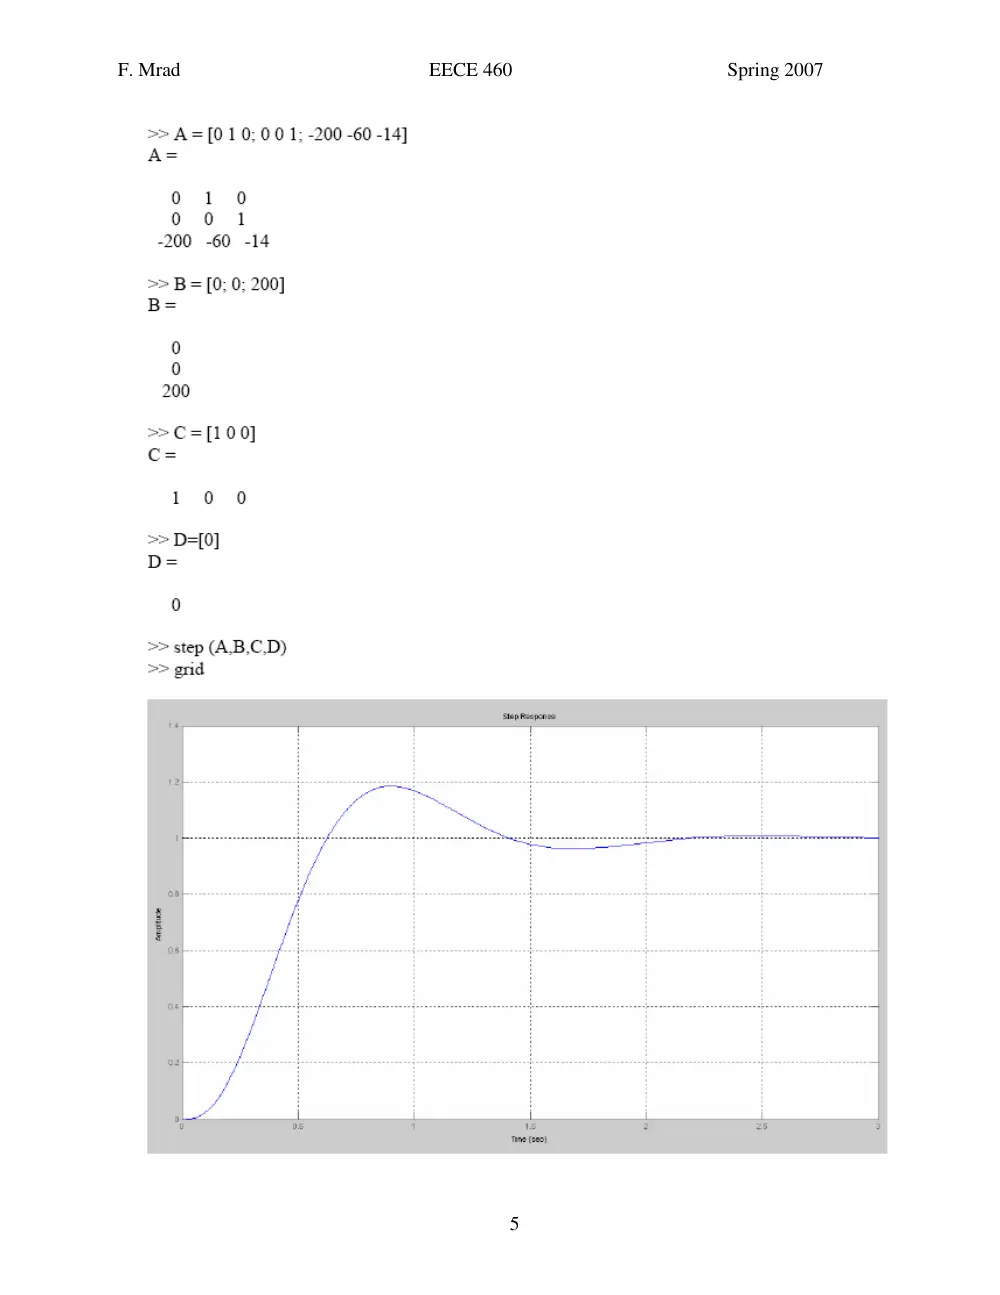
The unit-step response of the desiqned system can be obtained from Equations
(1) and (2) by substituting r = 1(t) and finding y(t). A MATLAB program to
obtain the unit-step response curve [y(t) versus t curve] is given on the next
Page. : ‘
F. Mrad EECE 460 Spring 2007
>> A=[0 10:00 1: -200 -60 -14]
A=
o 1 0
0 0 1
-200 -60 -14
>> B=[0: 0: 200]
B=
0
0
200
>> C=[100]
c=
1 0 0
>> step (A.B.C.D)
>> grid
F. Mrad EECE 460 Spring 2007
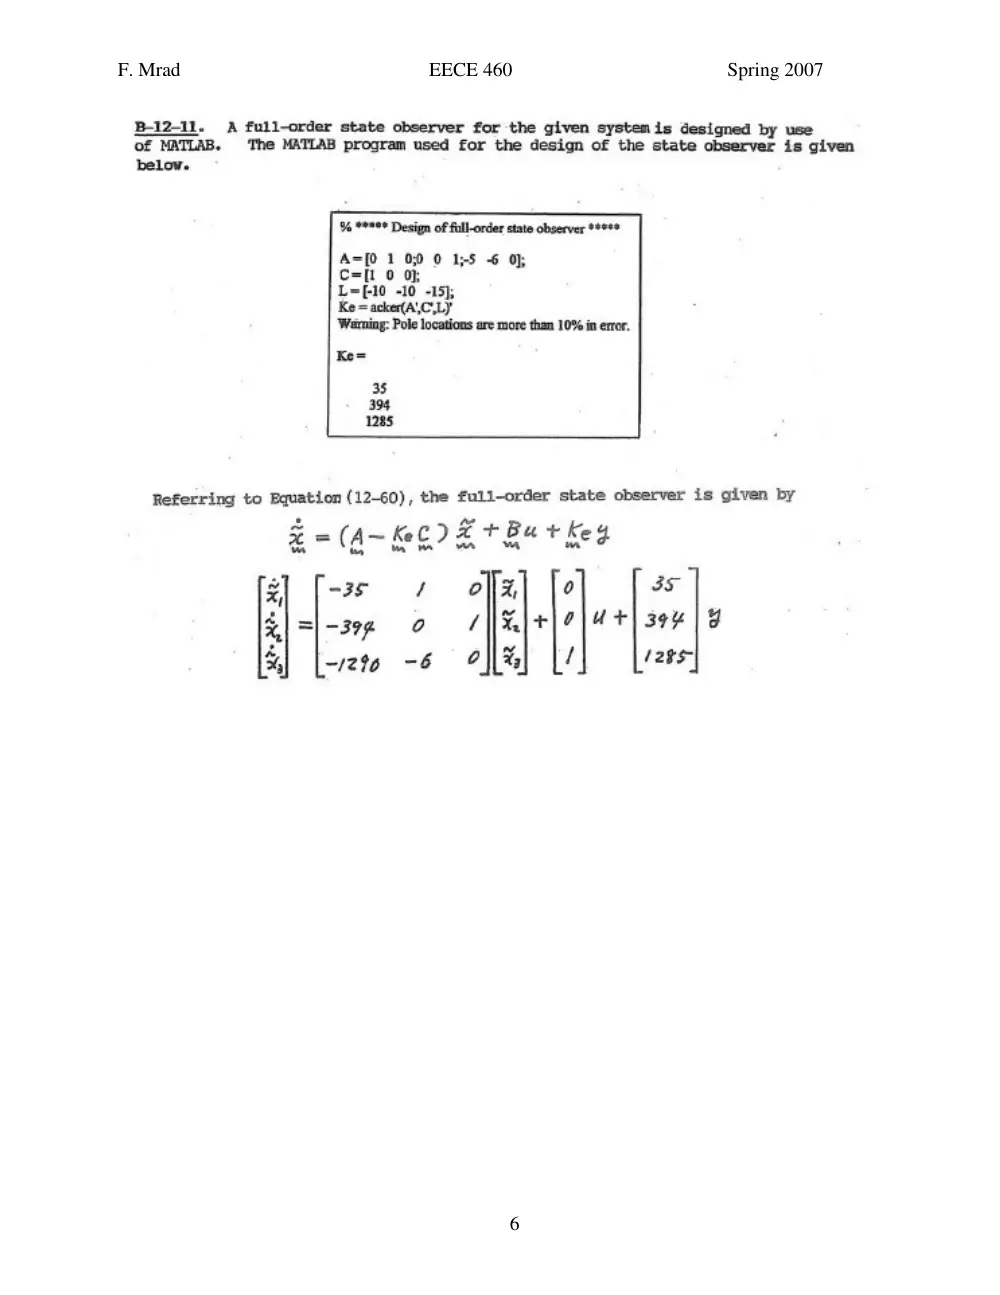
B-12-11. A full-order state observer for the given systemis designed by use
of MATLAB. The MATLAB program used for the design of the state observer is given
below.
fe ***" Design of full-order state observer *****
A=[0 1 00 0 1-5 4 O;
C=[1 0 oO;
L=[-10 -10' -15];
Ke =acker(A\C\Ly
‘Warning: Pole locations are more than 10% in error.
Ke=
35
394
1285
Referring to Equation (12-60), the full-order state observer is given by
Zo (4~ QQ Et Bat kes
=
g| [-35 7 off%| |e oS
aa -/{2%6 -6§ 4] %, ed fare
F. Mrad EECE 460 Spring 2007
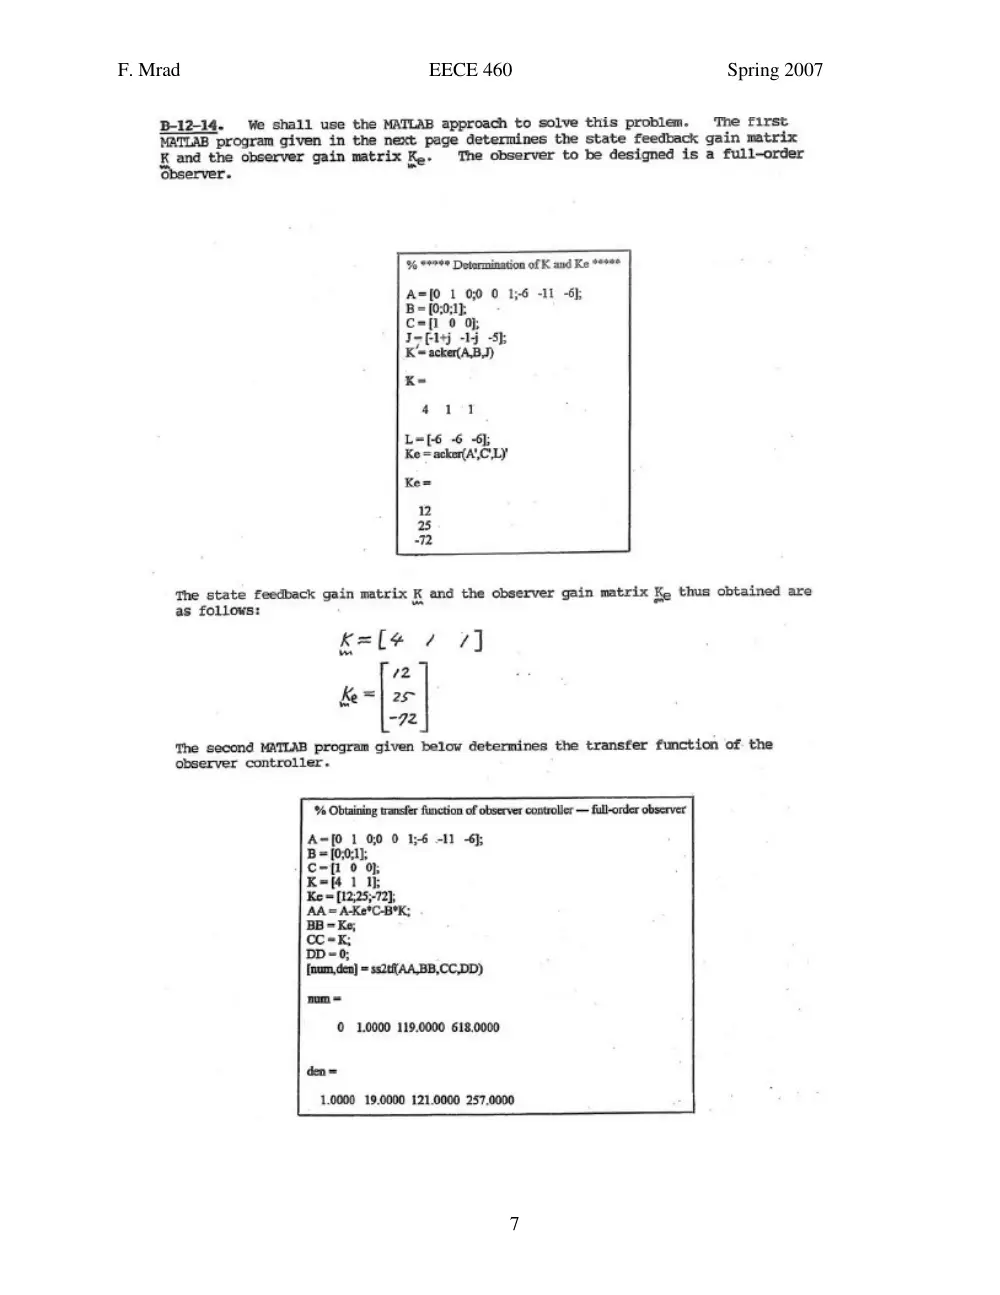
B-12-14. We shall use the MATLAB approach to solve this problem. The first
MATLAB program given in the next page determines the state feedback gain matrix
BR and the observer gain matrix K, The observer to be designed is a full-order
erver.
% ***** Determination of K and Ke *****
A=[0 1 0;0 0 1,6 -I1 -6h;
B=[001;
C=[l 0 of
Infly -li 3k
K's acker(ABJ)
The state feedback gain matrix K and the observer gain matrix Ke thus obtained are
as follows:
Kk=(# ¢ 7]
12
Ke =| 25>
~F2
The second MATLAB program given below determines the transfer fimetion of the
observer controller.
% Obtaining transfer function of observer controller — full-order observer
Aw[0 1 0,0 0 1-6 -11 6;
B= (0,01);
|c-fi 0 of
K=f4 1 I;
Ke = [12,25,-72],
AA = A-RetC-BPk;
BB = Ke,
cC=K;
DD=0;
[num, den] = ss2tf{AA,BB,CC,DD)
0 1.0000 119.0000 618.0000
én=
1.0000 19,0000 121.0000 257.0000
F. Mrad EECE 460 Spring 2007
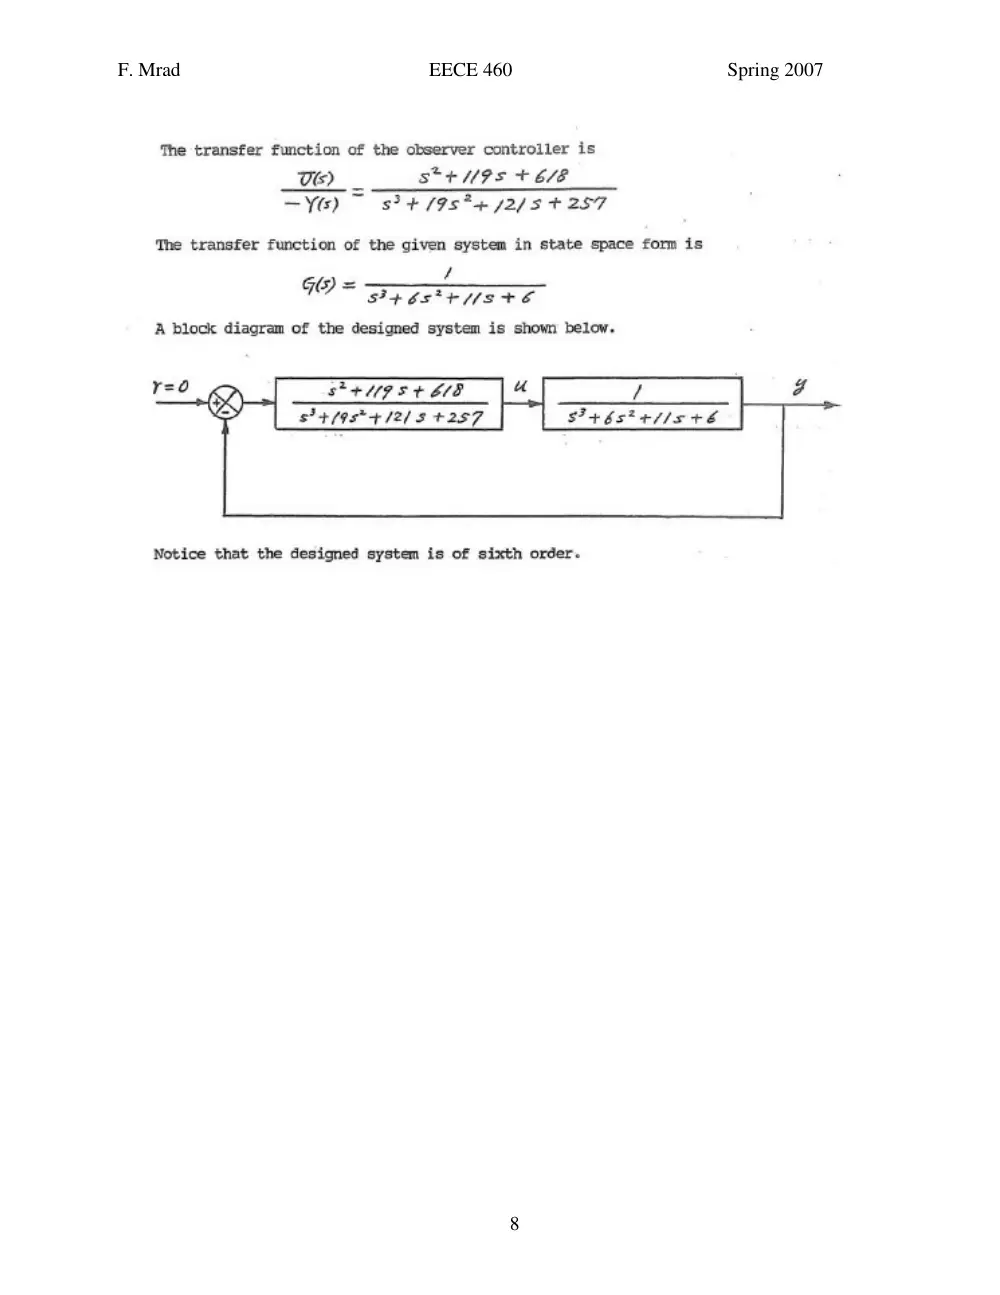
The transfer function of the observer controiler is
ee) S*tHPs + é/8
—Yts) ~ 33+ 9574/2434 257
The transfer function of the given system in state space form is
é
sty gs*+ffaté
A block diagram of the designed system is shown below.
Gi) =
sees t éf8
aot (Ps (2/3 +2357
/
Se4gsteeis té
Notice that the designed system is of sixth order.