
EECE 460 Homework, Spring 2008
American University of Beirut · Control Systems · 4 pages
More EECE 460 files
Show the text of this homework
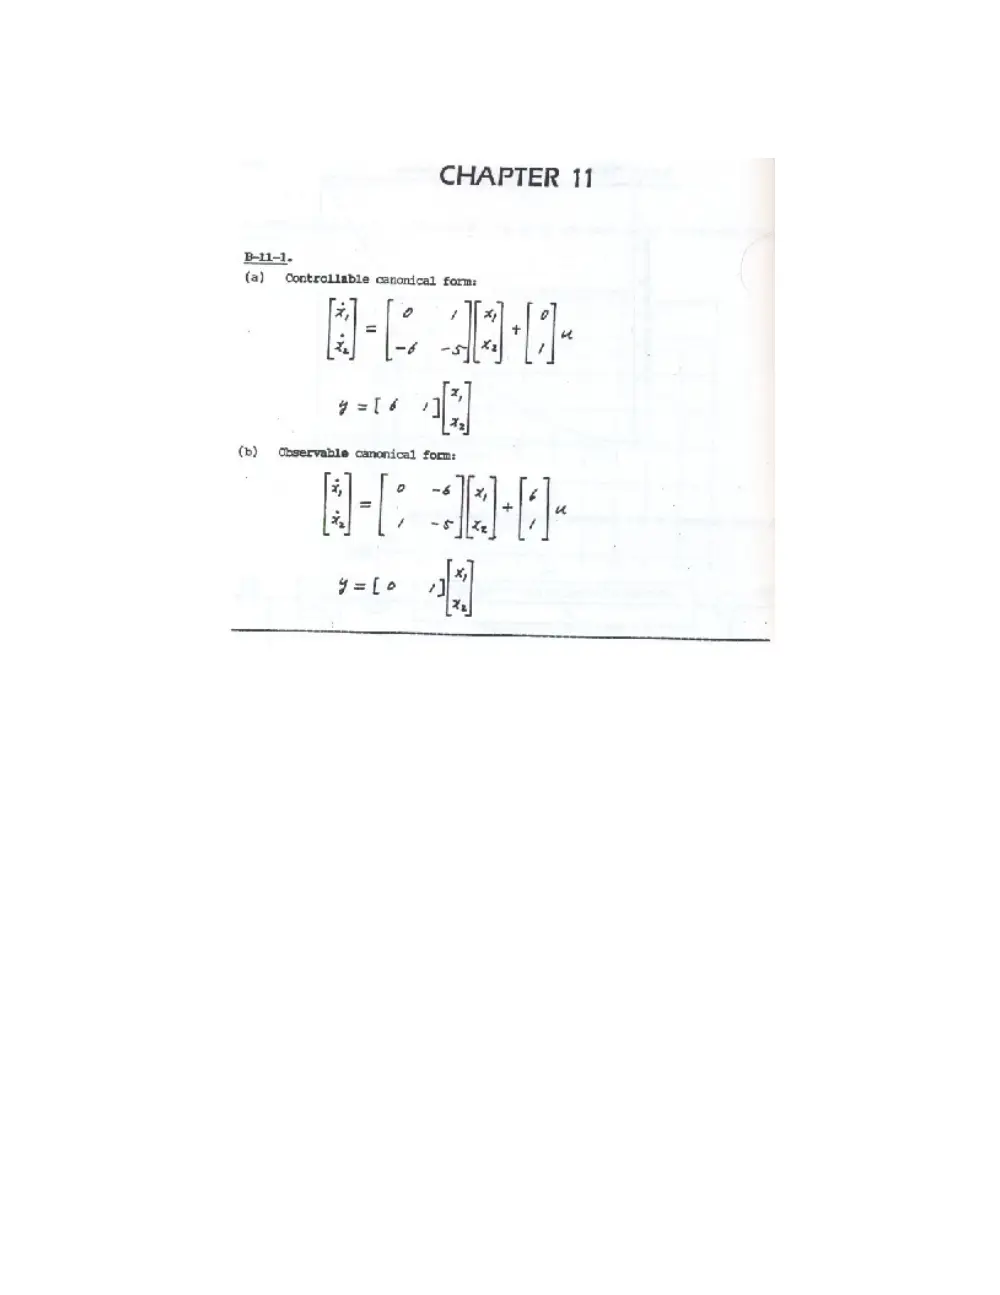
CHAPTER 11
B-11-1.
(a) Controllable canonical form:
EE [I
i
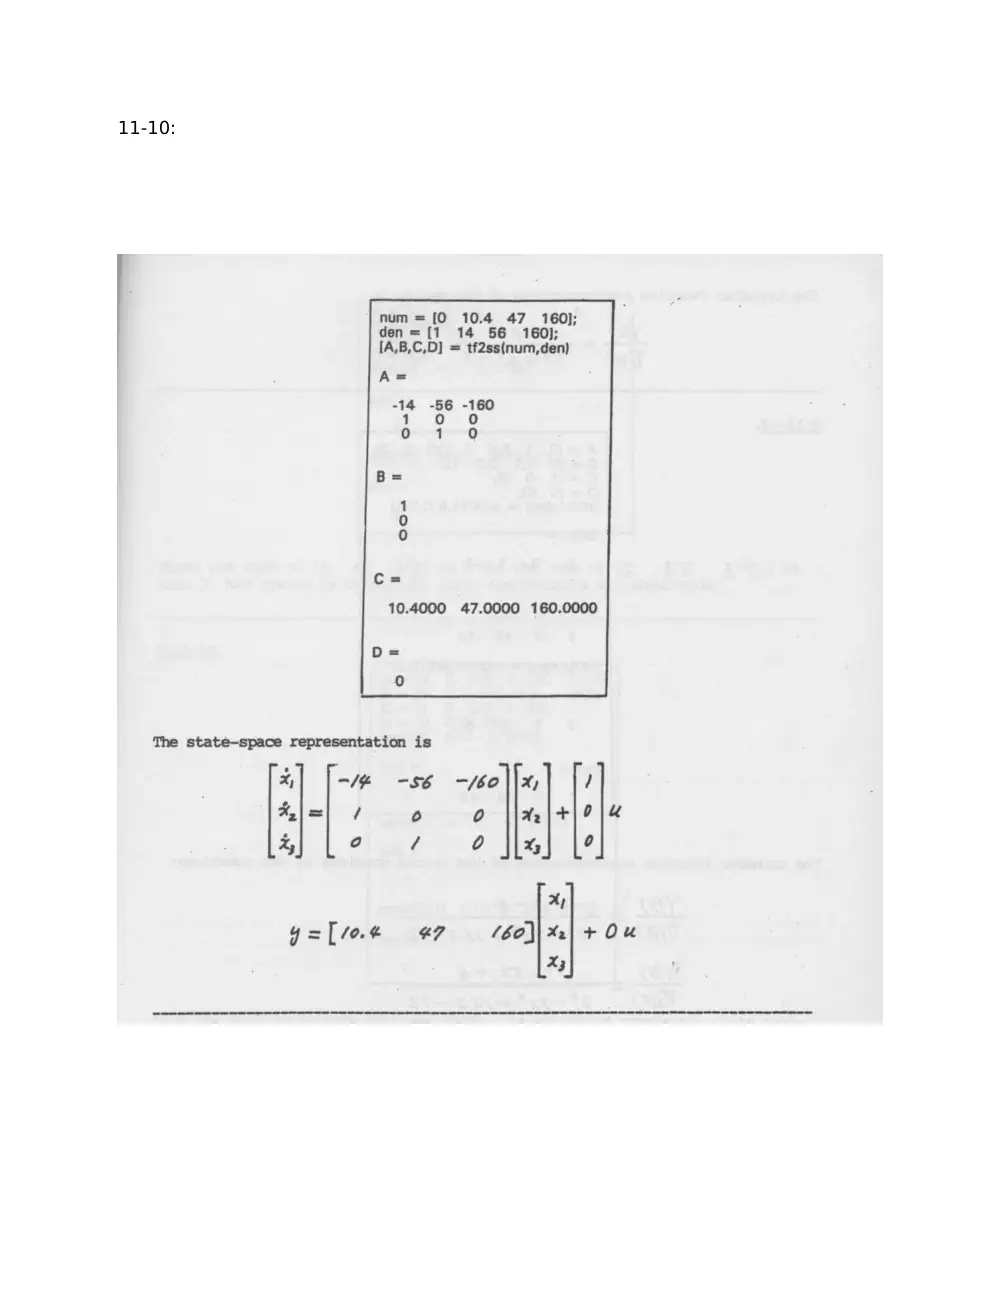
11-10:
num = [0 10.4 47 160];
den=[1 14 56 160];
[A,B,C,D] = tf2ss(num,den)
A=
-14 -56 -160
+ O-- 0
e198
The state-space representation is
x% “/¢% -SE —-/60)\|%) /
4) =| 7 } O |lae|+]9 14
% ) 7 Oly Q
ya=[7e.%@ 47 60))/%2|+ Ou
aa
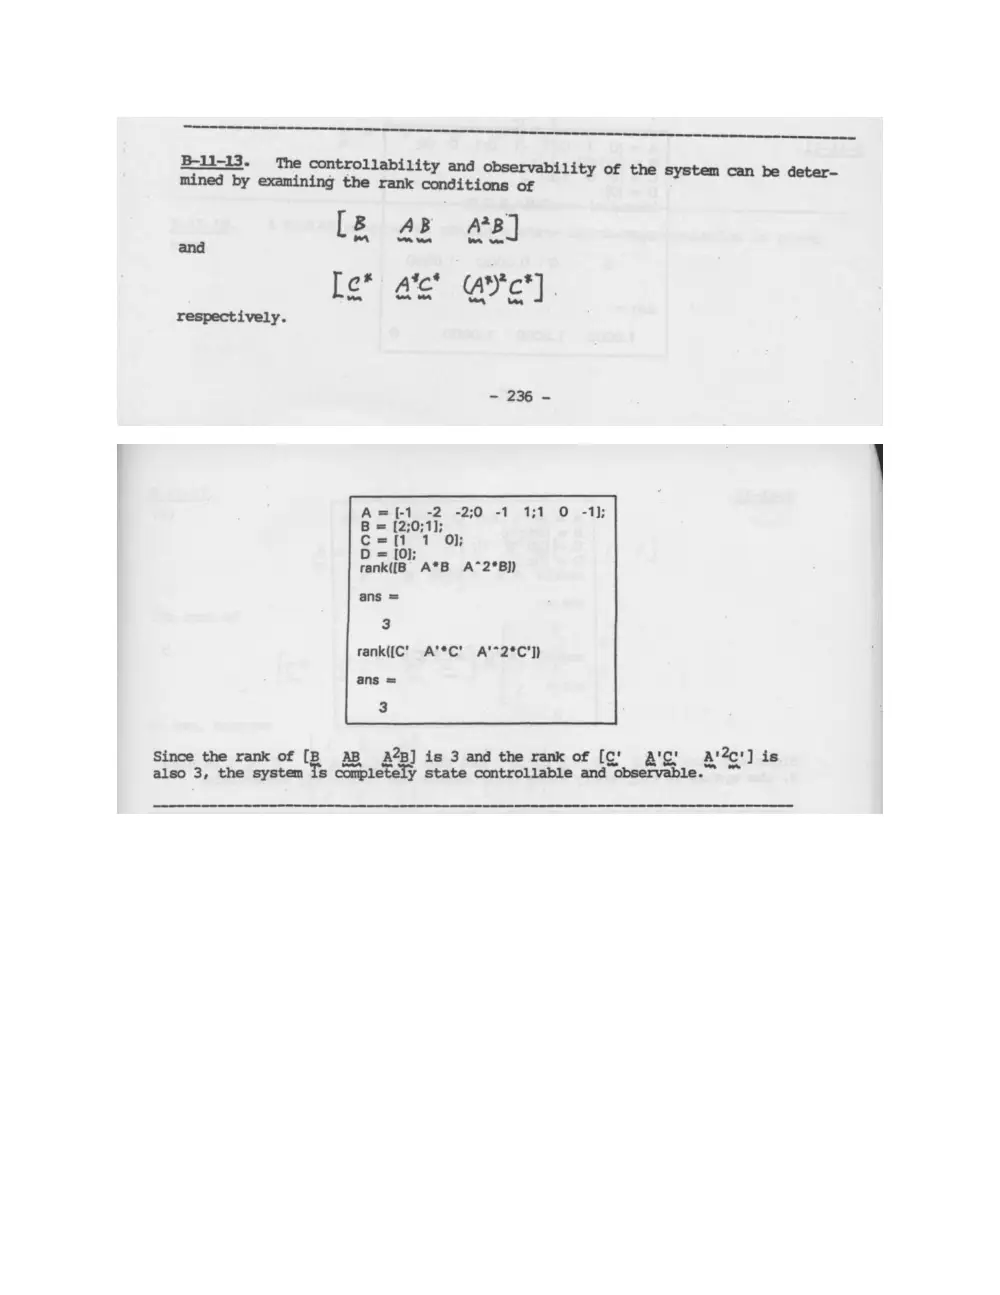
B-11-13. The controllability and observability of the system can be deter-
by examining the rank conditions of
[Eo Ak ae]
and
® tpt #)\% -*
[e* afc @vtct].
respectively.
—206-=
A=[-1 -2 -2;0 -1 1;1 O -1);
B = [2;0;1];
is
rank([B A*B A*2*B))
ans =
3
rank([C' A'*C' A'*2*C'))
ans =
Since the rank of [B AB Aig: ai%cr] is
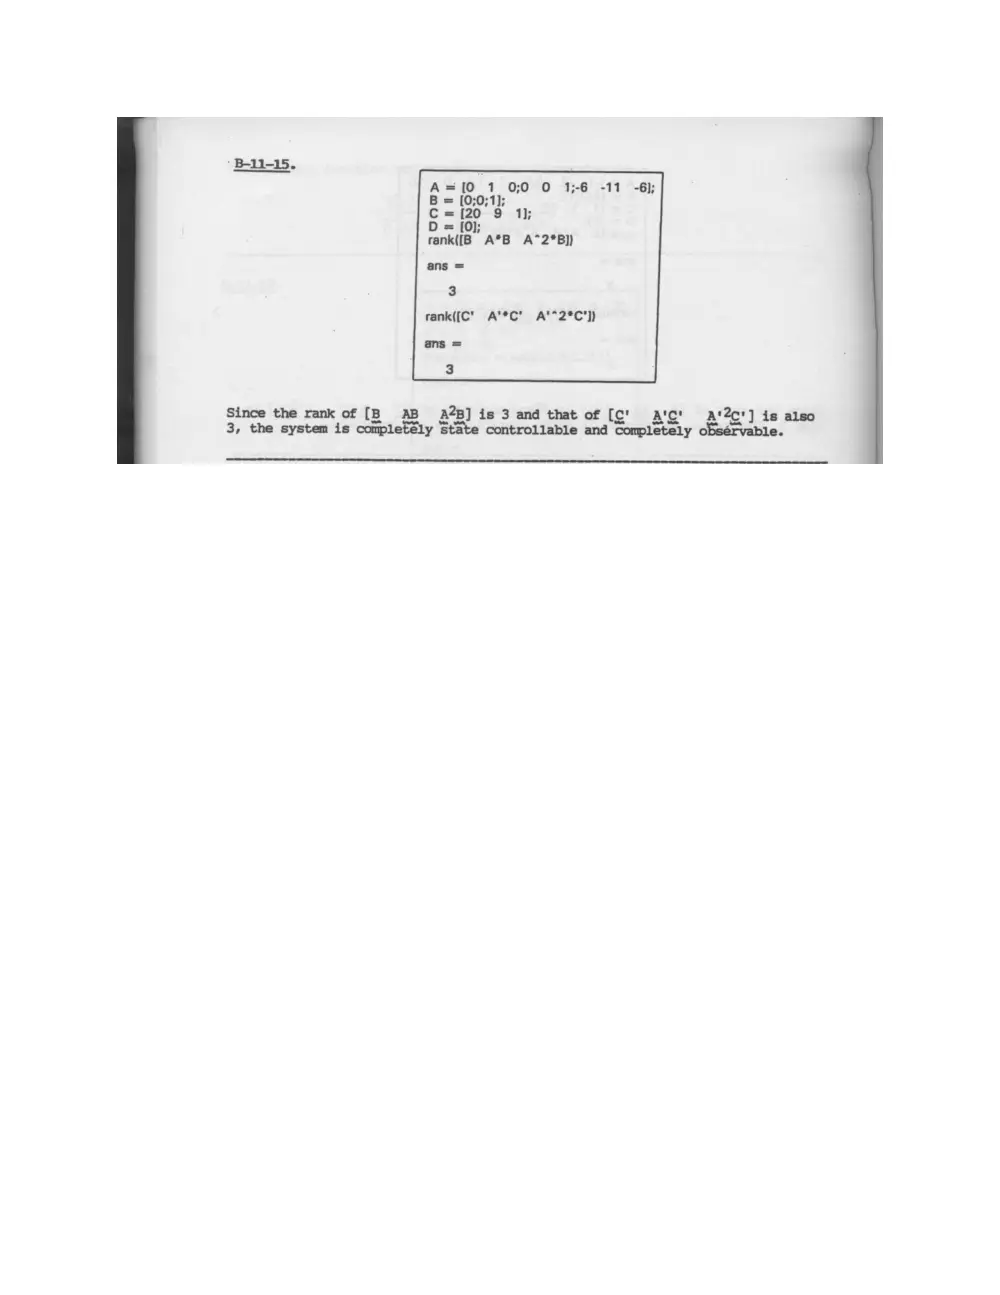
*B-11-15.
A=1[0 1 0,0 O 1;-6 -11 -6);
B = [0;0;1];
C=[20 9 1];
D = [0);
rank([B A*B A*2*B))
ans =
3
rank([C'
A‘*2*C'))
At
ans =
3
Since the rank of [B AB 2B] is 3 and that of [C¢' A'c' a'2¢'] is also
S, the eyeteh le completely State Cae ceStahe anal Gaipleely Seeaiae: