
EECE 460 Homework, Spring 2008
American University of Beirut · Control Systems · 5 pages


More EECE 460 files
Show the text of this homework
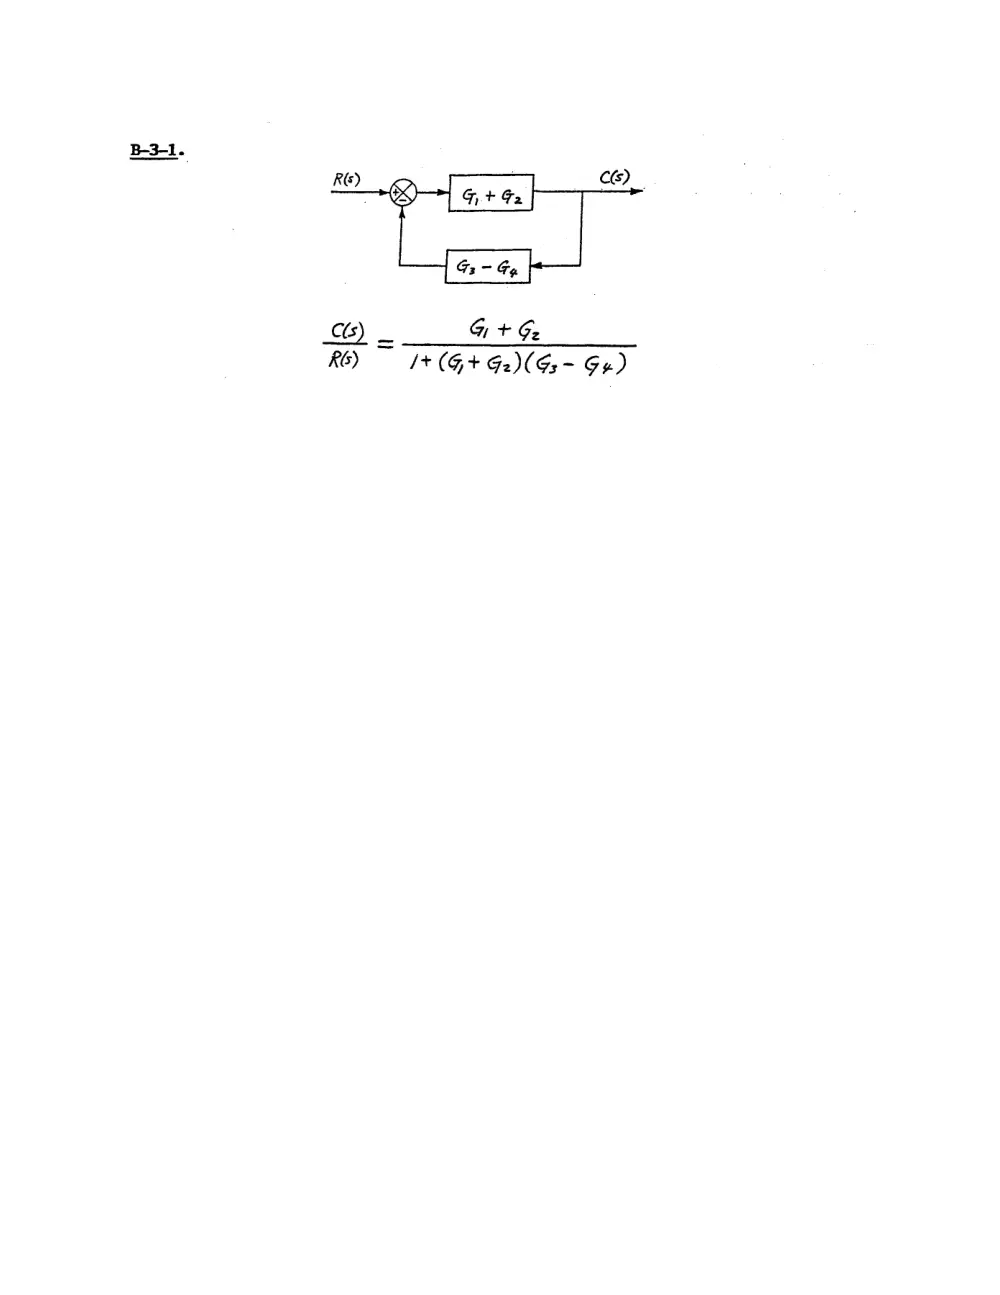
B31.
RG) I+ (G+ GaN Gs- Gu)
B-3-5. When D(s) is zero, the closed-loop transfer function Cp(s)/R(s) is
Ce) _ _ Ge ©) GL)
RID It Gels) Gp @)
When R(s) = 0, the closed-loop transfer function Cp(s)/D(s) is
Cr) _ /
DO —- 1+ Gel) Fe)
When both the reference input and disturbance input are present, the output C(s)
is the sum of Cp(s) and Cp(s). Hence
/
C= Gb)" Col = aseay
[ 5269 Gol? RE) + be]
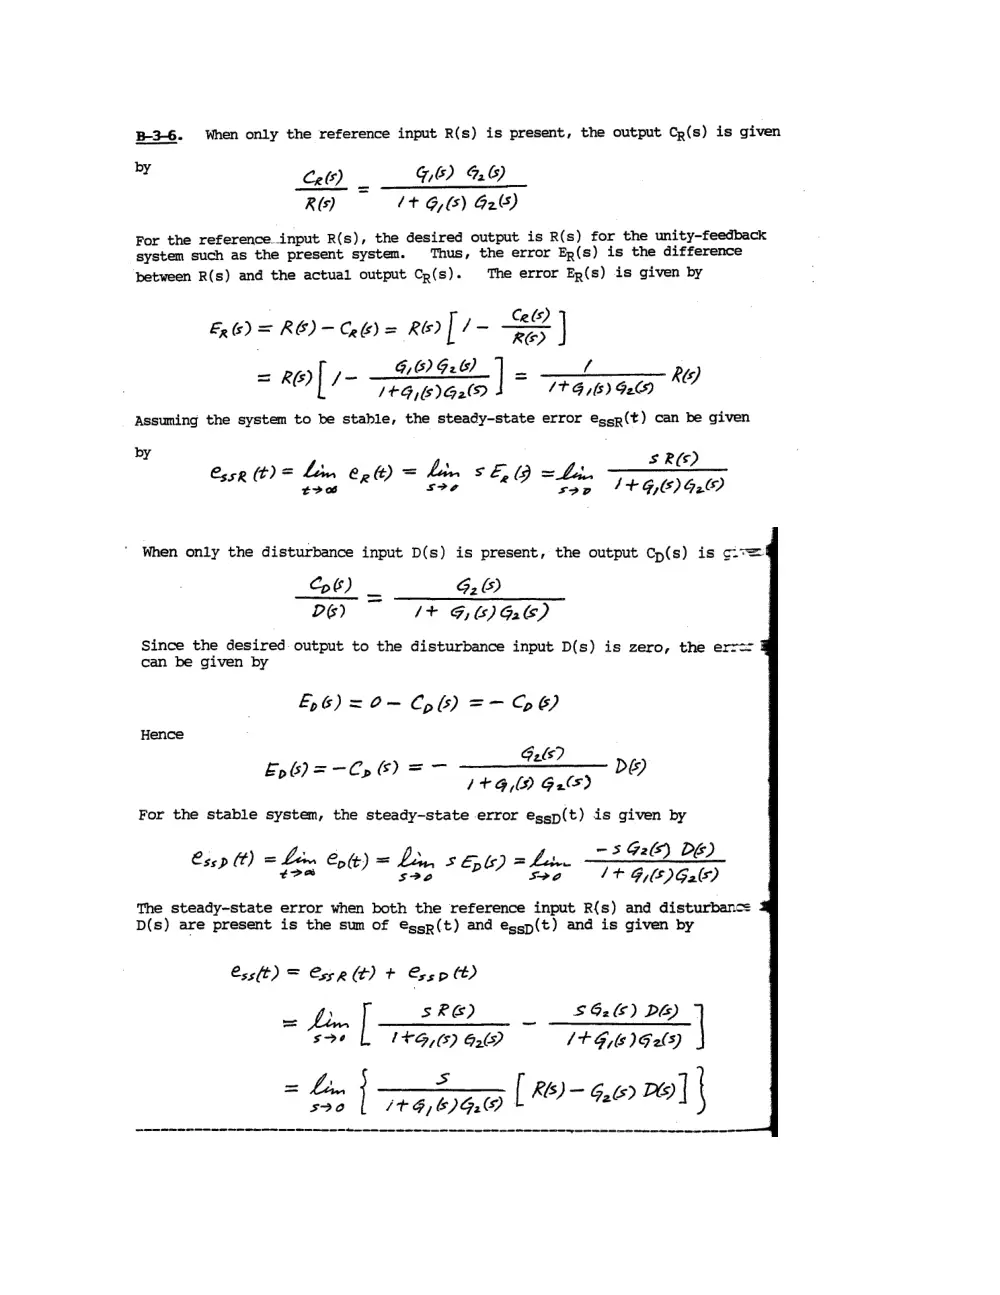
B-3-6. When only the reference input R(s) is present, the output Cp(s) is given
by Cee) __ 6) &O)
R@) ——si«E GS) G2)
For the reference.input R(s), the desired output is R(s) for the unity-feedback
system such as the present system. Thus, the error Ep(s) is the difference
between R(s) and the actual output Cp(s). The error Ep(s) is given by
Cels)
Eels) = RE) — Cel) = rey | /- EE |
_ _ G,6)G26) ] = / Res
~ Ren] / 7#G,6)G2O 1? Gil) G2) @
Assuming the system to be stable, the steady-state error Eggr(t) can be given
by sRe
= . = her s E, =k, —
Css (t) Lin Cet) = kim SEY bin 746,640
‘ When only the disturbance input D(s) is present, the output Cp(s) is c=
Cob) _ G62)
D6) 1+ G,6)GE)
Since the desired. output to the disturbance input D(s) is zero, the errcr
can be given by
£,6)=0-0)6) =-GH)
Hence
G25?
1+G,0 G2)
For the stable system, the steady-state error @gsp(t) is given by
: , -3G26) D&)
e @) = hewn e, = = bo 75 F206) C6)
wp) = Lox Cott) = Lin $ E56) = hits Tey
The steady-state error when both the reference input R({s) and disturbance
D(s) are present is the sum of @ggp(t) and eggp(t) and is given by
£p6)=—Cy 5) = — Do
Csslt) = Esser Zt) + Ess Ct)
_ l s PG) _ |
se '*G,6) G49 4+ G6 )G 25)
= Lo leas [ 28)- 6,0 De] |
f
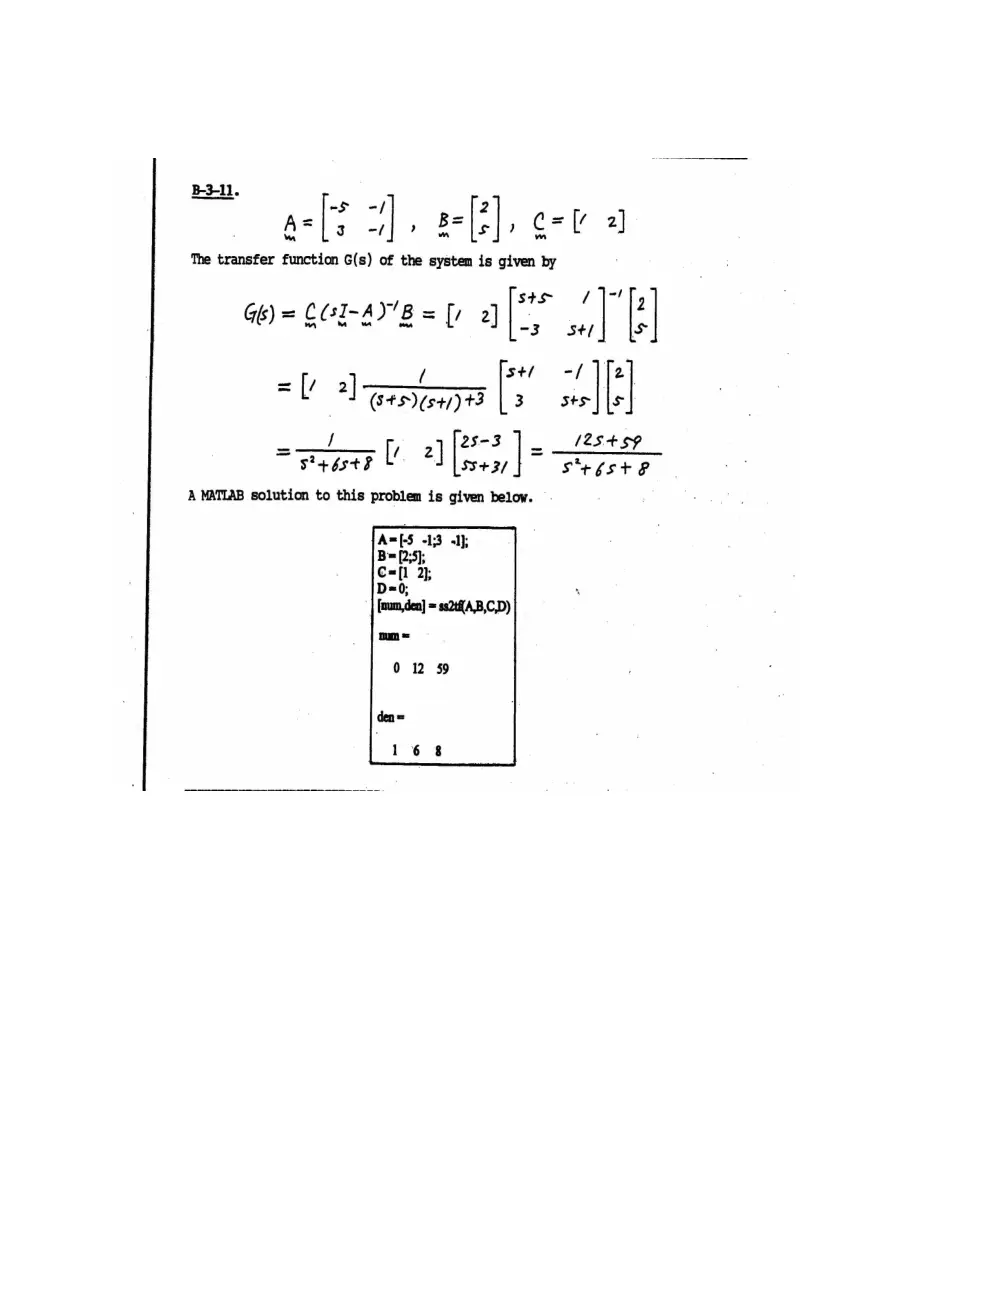
Define
Aragr+2gau
ae[2 ci), e[E], eb 2
Mw
The transfer function G(s) of the system is given by
Ge) = GUI-AN"B = [) 2] i I |
“3 St/ >
/ Sti -f |lat
lV a] (S#5-)(s+/) +3 ' a |
! [V2] [3 - 25459
S24 65th S34+3/ S*+6steP
A MATLAB solution to this problem is given below.
[uum dea] = se248A.B,C.D)
0 12 59
den =
16 8