
MECH 430 Notes 2, Spring 2014
American University of Beirut · Instrumentation and Measurements · 21 pages


Showing the first 10 of 21 pages. Download the PDF to see all of it.
More MECH 430 files
Show the text of this notes
Instrumentation & Measurements
MECH 430
MECH 430
Slide 1
Introduction
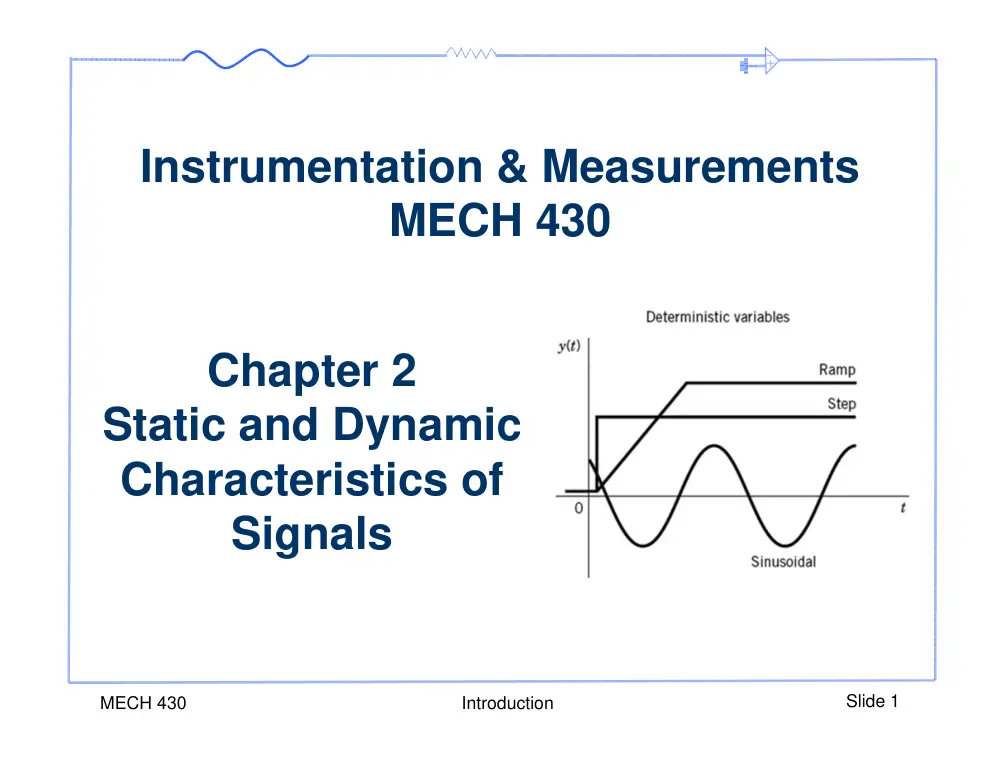
Chapter 2
Static and Dynamic
Characteristics of
Signals
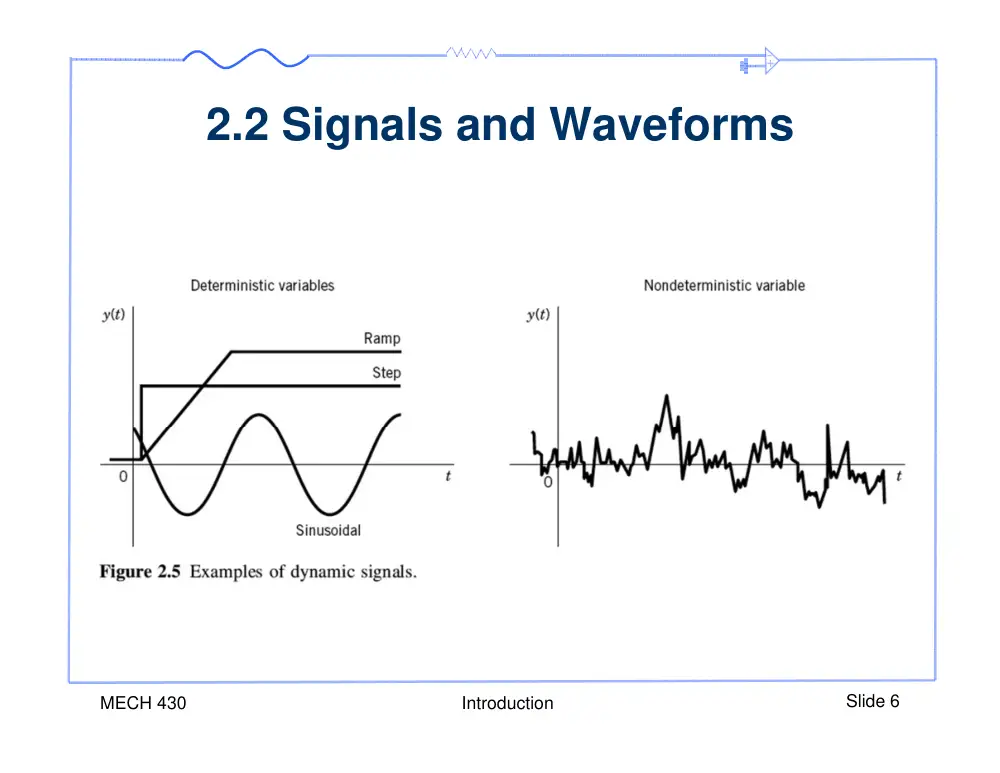
2.2 Signals and Waveforms
•
A signal is used to transmit information
•
In the context of measurement systems, both the input and the output have a
waveform, which can be represented as a signal.
•
Signals may be classified as:
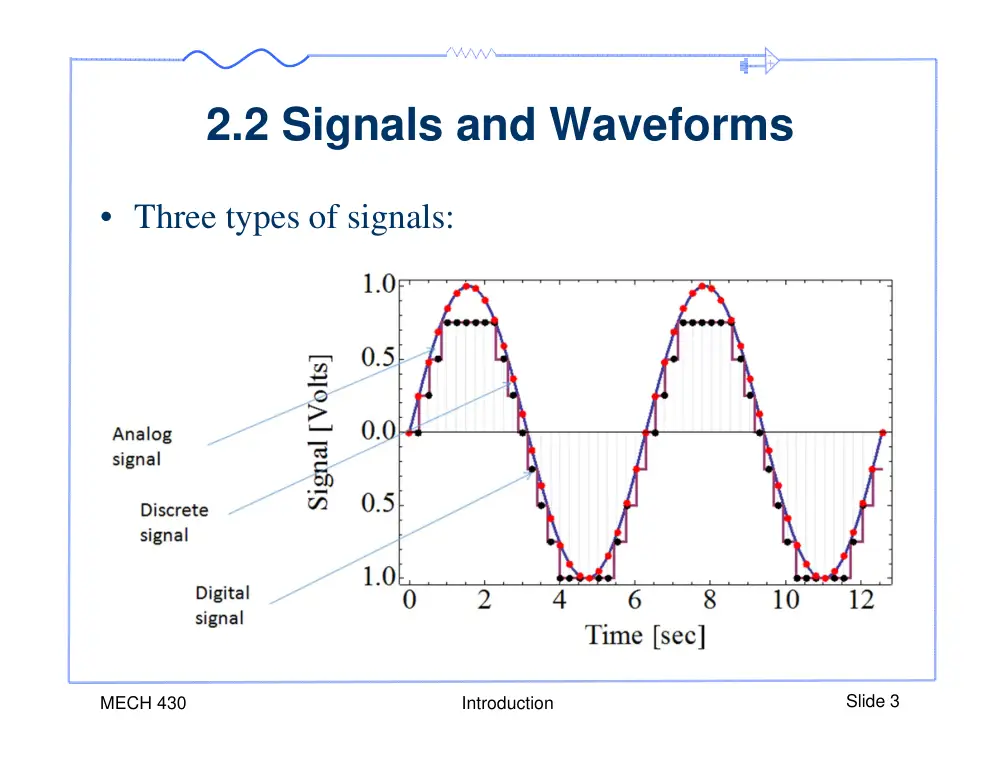
– Analog signals
– Discrete signals
– Digital signals
•
A Discrete Signal results from the sampling of an analog signal at repeated
finite time intervals. We estimate the value of the signal in between discrete
values by assuming it is equal to the last available value (Sample and
Hold).
•
The magnitude of a Digital Signal are also discrete by the effect of
Quantization.
MECH 430
Introduction
Slide 2
2.2 Signals and Waveforms
• Three types of signals:
MECH 430
Introduction
Slide 3
2.2 Signals and Waveforms
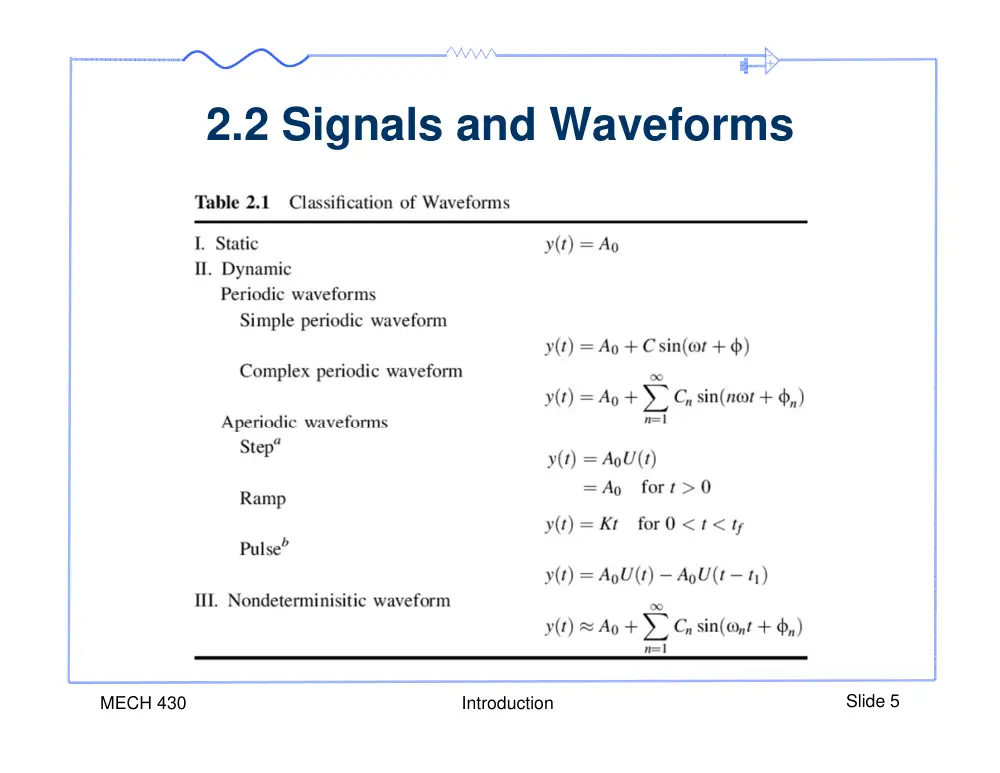
• Signals may also be characterized as static or
dynamic.
• A static signal does not vary with time, Example, the
diameter of a shaft. Voltage of a battery, outdoor
temperature?
• A Dynamic signal is a time dependent signal. They
can be deterministic or non-deterministic. They can
be simple periodic, complex periodic or aperiodic.
MECH 430
Introduction
Slide 4
2.2 Signals and Waveforms
MECH 430
Introduction
Slide 5
2.2 Signals and Waveforms
MECH 430
Introduction
Slide 6
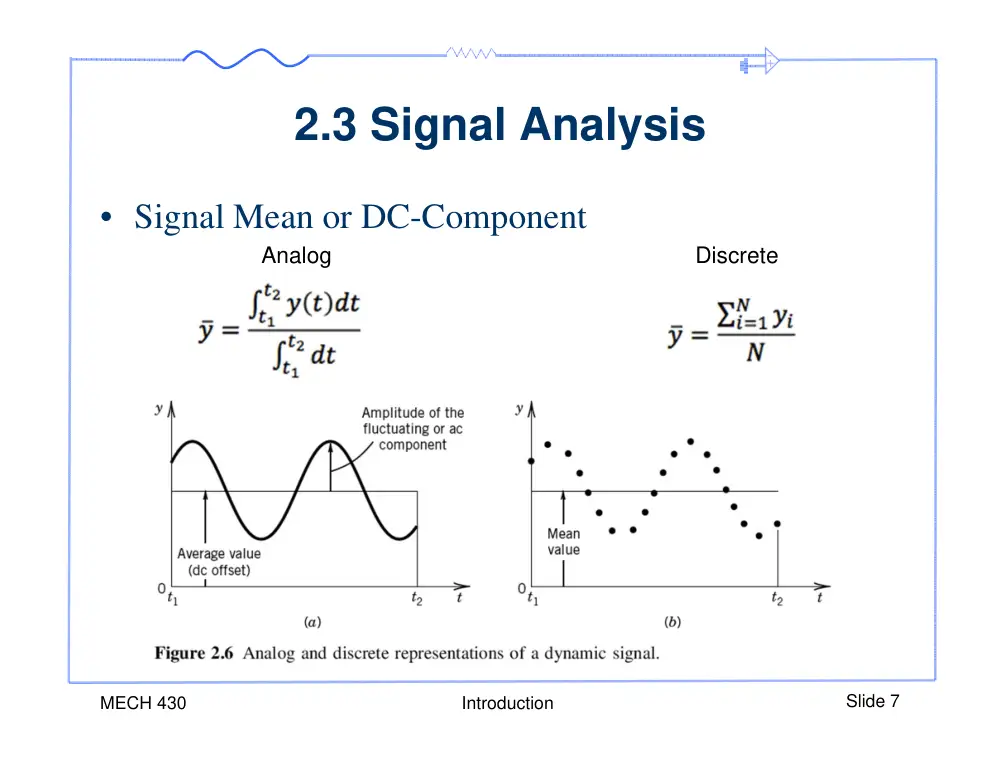
2.3 Signal Analysis
• Signal Mean or DC-Component
MECH 430
Introduction
Slide 7
Analog
Discrete
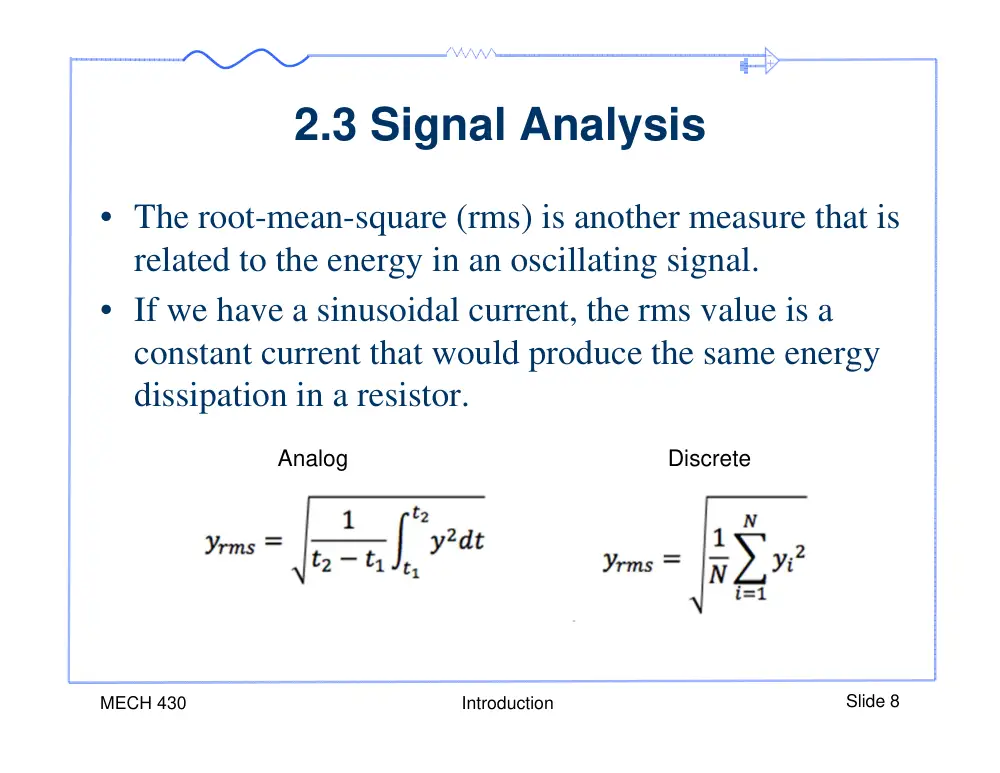
2.3 Signal Analysis
• The root-mean-square (rms) is another measure that is
related to the energy in an oscillating signal.
• If we have a sinusoidal current, the rms value is a
constant current that would produce the same energy
dissipation in a resistor.
MECH 430
Introduction
Slide 8
Analog
Discrete
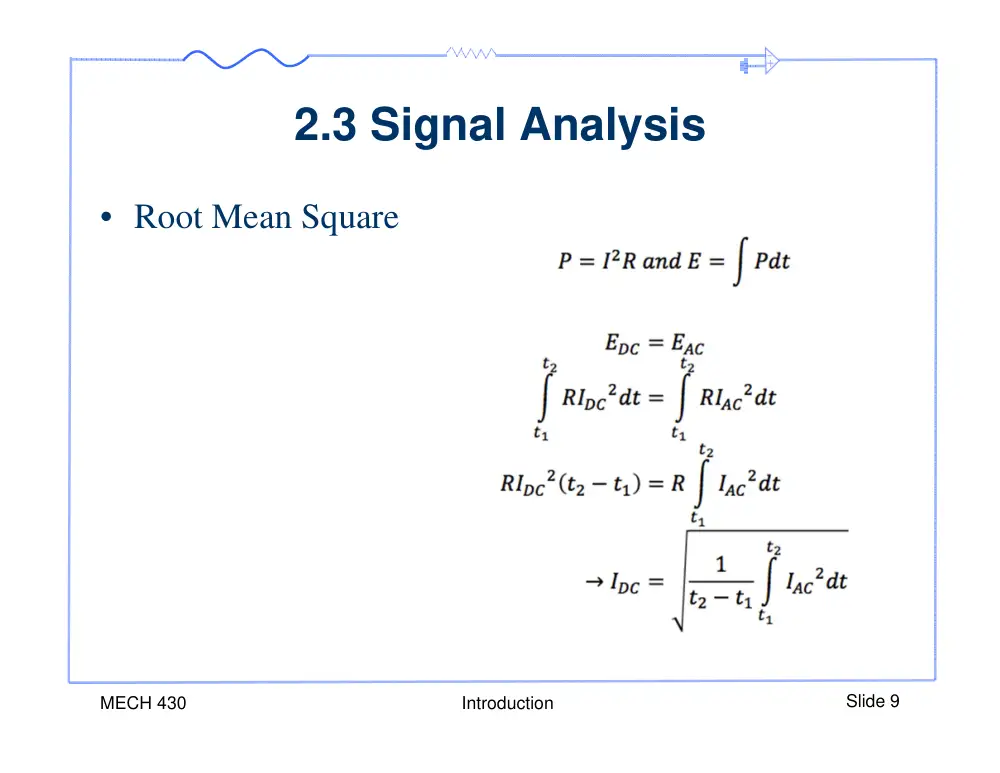
2.3 Signal Analysis
• Root Mean Square
MECH 430
Introduction
Slide 9
2.4 Signal Amplitude and Freq
MECH 430
Introduction
Slide 10
Radial
Fourier Series
• In many cases, signals do not have a clearly defined
trigonometric form.
• We can represent such signal as a weighted sum of
sinusoidal signals (sines and cosines).
• This decomposition into an infinite number of sines
and cosines is called a Fourier series.
MECH 430
Introduction
Slide 11
Fourier Series
MECH 430
Introduction
Slide 12
Fourier Series
MECH 430
Introduction
Slide 13
Frequency content of white light
MECH 430
Introduction
Slide 14
Example
MECH 430
Introduction
Slide 15
-
Example
• This is an odd function then the DC component is zero and the
cosine coefficients are all zeros.
• The sine coefficients
MECH 430
Introduction
Slide 16
Example
• Use tools to compute integrals
• Take a look at http://www.wolframalpha.com
MECH 430
Introduction
Slide 17
Example
MECH 430
Introduction
Slide 18
Note that the yellow line represents the sum of the first three terms
-
Example
MECH 430
Introduction
Slide 19
Example
MECH 430
Introduction
Slide 20
Example
MECH 430
Introduction
Slide 21